I am so excited to share my adventures from this week with you! Let’s start with a routine update of the work I’ve been able to accomplish this week, and then I’ll tell you about my super-exciting mini oceanography cruise.
After my presentation last week, I’ve pivoted gears from simply researching data science solutions to really digging into generating a proof of concept. I say all of this, but of course, I spent the majority of this week setting up, installing, and configuring the necessary software for that proof of concept. It turns out that deep-sea robots are incredibly complex—and that’s after all the work has already been done to make them! Just “plugging in” to the system, so to speak, is an endeavor all by itself.
So, this week I spent a lot of time jumping down various rabbit holes in order to correctly set up ROS (Robotic Operating System) on a virtual machine, and I finally have it up and running. I was even able to run this really cool simulation of Sentry.
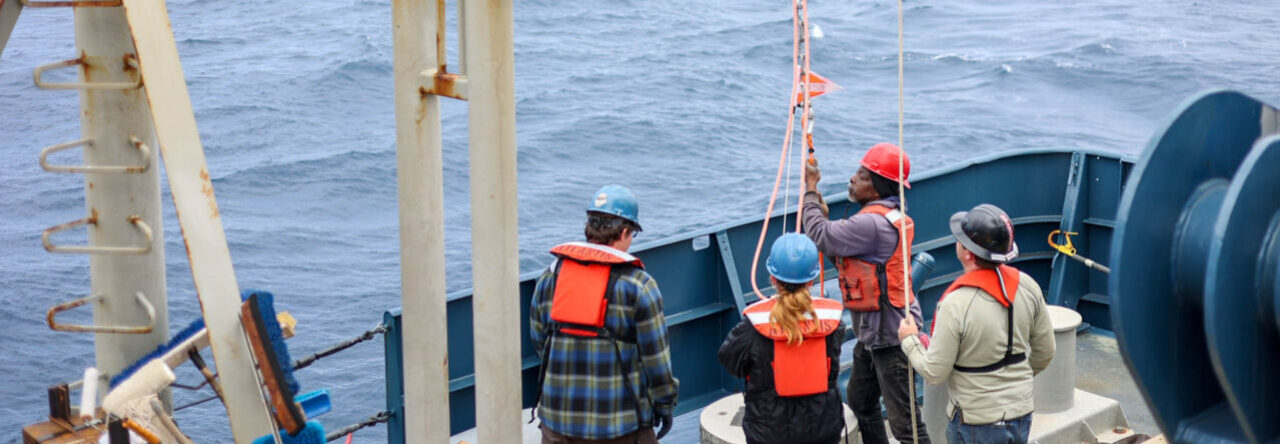
Separately, this week I had the opportunity to go on a short, few-hours-long intro-to-field-oceanography cruise! We boarded the ship—a small but decently sized fishing vessel owned by a community member who participates in a large amount of citizen science here at WHOI—and cruised out of the harbor.
We deployed a camera tow and were able to visualize and inspect eel grass forests. It was a bit choppy in the channel, so we weren’t able to see as much as we had hoped with the camera, unfortunately. But the best part was yet to come—we deployed a number of catchment vessels to pull up some critters to research! We dredged a small section of the bottom, used a floating plankton catcher, and deployed a lobster pot.
Here are some more pictures from that short but sweet adventure:
Hope you enjoyed the pictures—I hope they made up for last week’s lack!
This week was jam-packed with a variety of activities and opportunities to learn!
On Wednesday, the AOPE (Applied Ocean Physics and Engineering) staff held scientific presentations, where scientists and engineers gave lightning-round talks about their current research and past findings. It was really cool to hear about the huuuuuge variety of things people are researching—all within the same department.
For example, many scientists are investigating the role and dynamics of sea ice and glaciers. Others are studying the health of kelp forests in South Africa and creating an accessible online map of the world’s giant (and other) kelp forests. Through the website, you can go back—say, 50 years—and explore how the forests have grown or disappeared over time.
In contrast, some researchers are using machine learning and artificial intelligence to “train” robots to swim gracefully—or, more scientifically, to move hydrodynamically through the ocean. Instead of brute-forcing their way through the water, these robots use physics and optimized movement to their advantage.
These are just two extremes of the research happening within the AOPE department. When I compare that to the work I’m doing in the DSL, and the work of those around me, it really highlights the incredible breadth of AOPE’s mission. You can also see how all of these pieces come together. For example, I can envision the data collected by Sentry (the deep-sea robot my team works on) being used to analyze certain oceanic plumes. Those findings, in turn, could help explain why certain oceanic vegetation—like giant kelp—is thriving or not.
There’s a chain of research and a cycle of knowledge that flows not just from Sentry and our robotics teams to external scientists, but internally as well. That’s part of what makes WHOI function so exceptionally.
Back to my work—this week, I had my mid-internship design review and presented my findings on data management for the Sentry machine learning pipeline to members of the Sentry team. The presentation went great, and the feedback I received will serve as a strong foundation for bringing Sentry into the future.
I deeply apologize for the lack of pictures this week—although, that probably gives you an accurate sense of how focused I’ve been on preparing for my presentation!
It is currently day 10 aboard the USCGC Healy! Kaleigh and I have received the full onboarding experience, including donning our survival suits. These ones are extra nifty, and can even hook together so you don’t drift apart. They remind me of how otters hold hands while they sleep! Making sure that everyone knows exactly how to don a survival suit ensures that, in the event of an emergency, it is a quick process with no confusion. Reaction time makes a huge difference in dangerous situations at sea!
Along these same lines, we ran many drills. Most of them were for the sake of Coast Guard training, but they are vital for everyone on the ship. Man overboard, fire, gas leak, and medical emergencies are some of the various drills that are practiced frequently. Practice doesn’t make perfect, but it does make for efficient response times. Everyone knows their duty and where their muster station is. Confidence in ability is half the battle!
Coefficients, variables, offsets oh my!
The marine technicians onboard the Healy run 24hrs a day, in 12 hour shifts. I am on the midnight to noon shift with my mentor Maya, and Kaleigh is on the noon to midnight shift with Tyler. The tech lead of our team, Christina, is on watch from 0600 to 1800. Having this overlap ensures that our turnovers go smoothly, and adds an extra hand to the times when science is most likely to occur on the cruise. This setup does mean that I don’t get to participate as much in the science, but gives a realistic view into the life of a technician.
In this photo, Christina (left) and Maya (right) are troubleshooting one of the many softwares that keep science aboard running. On the wall of monitors, each system can be observed at a glance. Generally, green lights mean things are running well, and red ones mean things need to be checked. Hope you aren’t color blind!
Though having this many screens may seem overwhelming, it is an asset. Nothing can be forgotten when it’s right in front of you!
Gravimeter, don’t bring me down…
Being a marine technician has much to do with variety. Having a wide scope of skills and working with many different instruments means always learning. A new piece of equipment for me is the gravimeter. Measuring marine gravity is an interesting science, and a subject that I know little about. I won’t bore you with the details, but check out this short, informational video for more info. My mentor Maya walked me through the process of a weekly test called “Test points”, where we use a multimeter to check resistances. We track the numbers in a spreadsheet, as well as enter the numbers into the deck box for calibrations sake. Next week, it will be my turn to teach Kaleigh, our other intern, how to perform the test.
While on watch, we make several rounds throughout the ship, touring through any space that has equipment and instruments under our supervision. We inspect deck boxes and cables, and remain vigilant for alarms, red lights, or low fluids. One of those spaces is the gravimeter chamber where the unit lives. I have come to quite enjoy our rounds, as it is a nice break from the lab, and we occasionally are able to see others up and about in the dead of night.
That pesky vent screw.No bueno…Takin’ a leak…
While transiting to science stations, it is a perfect time to test equipment. The CTD was due for a thorough look over, bottles and all. The day shift was working on sensors and the CTD “fish” itself, so it was up to the midnight marooners to test the niskin bottles. First up: do they hold water? Well, they were all full already. So the easy answer was yes! We drained them all out, giving us the chance to test the petcock drain on each bottle.
Interestingly, one bottle refused to drain, even with the vent screw wide open. After dismantling the bottle trying to troubleshoot, we found that it was the fault of a defective vent screw. The vent screw had no vent! A simple replacement solved the issue.
One of the spare bottles had a small leak, and we identified a crack right at the base of the bottles handle. Unfortunately, there is nothing we can do to repair the bottle, so it is simply out of commission. All the other bottles got the A-OK, so I clambered back up into the hangar loft and got the bottles back onto their storage rack.
Babies first sea ice!The Arctic Circle!
After a couple long days of work, we spotted our first patch of ice. And then another, and another! It’s official, we have entered into the Arctic Circle! This is definitely the most unique and incredible environment I have ever had the pleasure of experiencing. The farther North we chug, the thicker and more consistent the ice becomes. As it scrapes along the side of the hull, it sounds like a wild animal trying to escape the steel. The slow push against the floes sends cracks racing down the surface, and pierces the quiet air as a bullet through the fog. No polar bears yet, but we’re on the lookout always. Kaleigh is keeping a polar bear count in her blog posts, so be sure to keep an eye out for her updates as well!
The ice has quickly become a target of my fixation, and I wind down every day by just watching it float by. As an ice breaker, the Healy is specially equipped to come to areas that other ships are seldom able to traverse. As the ships local biology nerd, I am on the constant lookout for wildlife. Besides the occasional bird following the ship, there have been absolutely no signs of life up here in the ice. The binoculars are getting their fair share of sea time while we endlessly search the horizon for a polar bear, whale, or even just a seal. It is impossible to truly capture the ice and its presence in a photo, but it doesn’t mean I don’t keep trying!
I guess I better act right, or they might put me in here…
Another stop that we make on our daily rounds is the Mica stores. I have yet to find someone who can tell me why the space is called that, but it gets my Micah Stamp of Approval! A huge variable to take into account with science in the arctic is the cold, duh. Things have a tendency to freeze up here in all this ice! One of the systems that keeps things running smoothly are these ‘head tanks’. This creates a glycol-water mix for filling the transducer wells, which prevents freezing. Our only responsibility here is to check the levels, and to alert the engineering crew if they look low. We noticed that a few were low, so once they were freshly filled, we added labels to the level with the current date, for future reference.
You’re telling me farfalle doesn’t come out this end? Are you sure?
Another new piece of equipment I have encountered is this Lebus winch. I have worked with other winch types of winches before, but this one looks akin to a pasta maker! This machine is especially good at pulling loads with long lines and heavy instrument packages. It has special ‘gates’ that can be opened and closed to allow shackles and thimbles to be wound through with no problem. I have not been able to see this winch in action much yet, but I am hopeful that one of our science stations will be on my shift in the upcoming week!
Spaghetti…
Ice breaking is simultaneously an exciting and a rather dull activity. Essentially, once we arrive on station, we do donuts in the ship, which leaves us with some interesting track lines. We break the ice sheets up while steering in concentric circles at varying speed, which leaves behind a nice slushy spot in the middle for us to conduct our scientific endeavors within. Occasionally, we may get lucky, and our operation will happen right amidst a pool of open water, which saves hours of ice breaking. Either way, the science must go on!
As the sun sits stable on the horizon and watches us slowly crush the ice sheets, that’s all I’ve got for you today. At a balmy 2 degrees Celsius, I am hiking up my longjohns and getting to work!
No rest for the weary on a Coast Guard ship! My first morning on the Healy started with alarms—man overboard! Don’t worry, it was just the first of several shipboard safety drills that day to welcome us onboard. An abandon-ship drill later in the day brought me to the hangar, where Micah and I tested our ability to speedrun suiting up in immersion suits. As we did, an exciting announcement came over the speakers: we’d officially crossed into the Arctic Circle!
Micah and I demonstrating the unbreakable bond of marine safety preparedness.
Just one day later brought us something to show for our crossing: sea ice! I’ve found that no matter how much you stare at the glinting white and cyan shapes bobbing by, it never gets old. The Healy is an icebreaker ship capable of continuously breaking 4.5 feet of ice, or 10 feet when backing and ramming. The continuous shudder of icebreaking is definitely a unique feeling compared to the usual sway of open water. The ship’s hull is designed not to pierce through waves like most boats, but rather to slide up onto ice and crush it beneath its weight. Watching the ice break and churn alongside the ship is mesmerizing. I worry ice pictures may be beginning to outnumber dog pictures in my camera roll! Hopefully some polar bear pictures will bridge the gap…
Throughout the week, Tyler taught me systems essential to a marine tech’s job, like the Rolling Deck to Repository (R2R) data system and e-logging requests from the science crew. I also started learning about user datagram protocol (UDP) and virtual machines (VM), which we’ll likely get into more of later. Stay tuned! Tyler additionally gave me a crash course on more instruments, including the ADCP and gravimeter. The gravimeter is an instrument that detects tiny changes in the strength of the gravitational field to give us better insight into the geological topography under the ocean.
Our first big project was updating the CTD. CTD stands for conductivity (salinity), temperature, and depth (pressure), and is considered the “bread and butter” of marine tech. The CTD package is often mounted to a rosette that also holds other sensors and Niskin bottles to collect water at various depths as it is lowered into deep water. To make it a little more confusing, “CTD” often refers to the entire setup, not just the core instrument package.
The full CTD rosette in all its glory.Attaching new instruments onto the “fish!”
After a baseline deck test confirmed most of the system was in good shape, we discovered the fluorometer wasn’t working. A fluorometer is an instrument that can measure the fluorescence of the seawater to give an estimate of the volume of chlorophyll present, which indicates the primary production of phytoplankton (the photosynthesizing base of the marine food web). Using a power supply and multimeter, we confirmed it was faulty and tested its replacement along with new oxygen and colored dissolved organic matter (CDOM) sensors, which we would also be adding to the CTD.
While I had worked with a CTD previously, learning about how instruments work using frequency and voltage was a new and exciting lens to explore. Tyler emphasized the importance of matching instruments to their correct pinouts. This involved digging for the correct cables in the endless cable drawer down in the science hold, testing them with the multimeter, labeling them, and then securely routing and connecting the cables on the CTD. Attaching expensive instruments to something going thousands of meters down in the ocean can be a little nerve-wracking, so we made sure everything is neatly wired and secured using hose clamps, velcro, and zip ties. After updating calibration files in Seasave and running another deck test, everything was set.
Getting geared up! It’s always just about freezing outside.More ice!
This week had no shortage of exciting sidequests. I spent lots of time with the multibeam ensuring it was running as best it could with the racket of ice all around and turning it off when the bridge spotted marine mammals. Having the most dramatic flare of the week, the metal pole supporting the wind sensor on the forward jackstaff snapped, leaving the sensor’s cable to be the only thing to hold up both. Deeming it in need of an immediate fix, the ship came to a halt and Tyler climbed the dicey jackstaff ladder off the bow to safely take it down. I was just happy to support from the deck!
We also began some more standard deck work. As of today, we’ve recovered three moorings that have been collecting data in the Arctic Ocean for a couple of years. Navigating mooring recoveries with the added obstacles of constantly moving and refreezing sea ice has been a really interesting process to learn along the basics of winches, taglines (and also in this case, grappling hooks!). I’m looking forward to observing and potentially participating more in upcoming deck work.
This picture is dedicated to Tyler’s mom.Observing a mooring recovery!
As we tackle tasks big and small, I’m slowly gaining familiarity with the work of a marine tech and learning more each day. It’s hard to believe it’s only been a week! Don’t worry, though, the watertight doors and eating lunch for breakfast keep me humble. Until next week!
Polar bear count: 0.5*
*A Coast Guard public affairs specialist (PA) showed me a picture he took of one from far, far away during the first night onboard, but none have been seen since then. I did, however, spot some walruses swimming in the distance!
Belated post (ironically) due to technical difficulties! Originally written July 16, 2025.
It’s been a busy few days! This week, I traveled to join the Healy, but evidently, I didn’t even need to hop on a plane to meet my MATE mentor, Tyler! As I lined up to board my flight from Portland, Oregon, to Anchorage, Alaska, Tyler found me and introduced himself. He’s a marine technician at Oregon State University, coincidentally my alma mater! He was a MATE intern a few years ago who was mentored by other previous MATE interns, so I’m stoked to be reaping the benefits of a long line of program successes. I’m in good hands!
Tyler works on the Ship-based Technical Support in the Arctic (STARC) contract, which essentially provides marine techs for the USCGC Healy’s science missions. Although the Healy is first and foremost a Coast Guard vessel, it’s also a research vessel. The cruise I’m on now is in support of the Arctic Mobile Observing System (AMOS), a network of autonomous oceanographic instruments making long-scale autonomous observations of ocean and sea ice physics.
In Anchorage, we met up with Micah, the long-term MATE intern joining for the same leg of this expedition. Soon, we were all on the short flight to Nome, a small town known for being the last stop in the famous Iditarod dogsled race. There, we met a member of the Coast Guard and spent roughly the next couple of blustery days banding together to explore Nome’s historical landmarks, gift shops, and eclectically remote dining options while waiting for the Healy’s arrival. Highlights included seeing wild musk oxen, finding the finish line of the Iditarod, and ordering sushi at a pizza restaurant.
Musk oxen right outside town!Shoutout to my third-grade teacher for instilling a love of both science and the Iditarod in me!
Once the Healy was in position off the coast of Nome, we coordinated with more newly arrived Coast Guard officers for our onboarding. Suddenly a bright and sunny day after a perpetual rainy gray, we made our way to Nome’s port. There, one of the Healy’s small boats (just 26 feet long!) picked us up in small groups while a water taxi transferred our luggage. As an understatement, the small boat ride was awesome. Wearing a Mustang suit, speeding along up and down through waves on an endless sunny sea as the grand profile of the Healy grew closer and closer was definitely a cinematic experience.
Oversized and extra warm mustang suits!Off we go! (Can you see me waving?)
When we reached the Healy (a whopping 420 feet in length), we were faced with our next new and novel experience: climbing a Jacob’s ladder dangling off the Healy’s deck while our small boat bumped through the waves next to it. Once I started climbing the swinging rope, I understood why its name carried the carnival connotation. Despite some nerves, I made it smoothly to the top and was officially on the Healy!
After climbing up, Micah and I were given a tour (lots of muscling through watertight doors) from the STARC lead onboard, Christina, then hauled our bags up and got settled in the computer lab. Then, once Tyler was onboard, the real work began! As we started north, Tyler showed me the “water wall,” the system of seawater that flows through a set of sensors for continuous data collection while underway. It gives us information about the current seawater temperature, salinity, oxygen, and chlorophyll levels. Configuring the water wall involves a “seesaw” of opening and closing valves to allow flow through the full arrangement of all the instruments with the right water pressure. Here, our main goal is to keep it flowing, accurate, and not explode it!
Off the bow of the Healy!Tyler adjusting the flow of the portside water wall.
Tyler also gave me a crash course in some key sonar instruments the STARC team monitors on the ship: the multibeam echosounder, singlebeam echosounder, and acoustic Doppler current profiler (ADCP). The multi-beam echosounder is an instrument that emits lots and lots of sound pulses to map out the seafloor like a 3D model by detecting how the frequencies change as they bounce back to it. The single-beam works similarly, but with just one pulse point, which provides us with a cross-sectional line of the seafloor topography. The ADCP uses sound to measure water current speed and direction by emitting sound pulses that bounce off particles suspended in the water. It then calculates the speed and direction of the current by measuring the Doppler shift, which is the change in frequency of the returning sounds.
Finishing up the first of my noon to midnight working days, we ended with a walk on the weather decks, admiring the almost-sunset off the land of the midnight sun. I’m so stoked to finally be onboard and excited for the steep learning curves ahead. Until next week!
Polar bear count: 0*
*Polar bears are not native to the Portland International Airport.
Well, hello again everyone! I hope you have had a restful few weeks, and are enjoying your summer to the fullest. My days at home were full of catching up with family and friends, eating out, and taking plenty of naps. I walked my dogs, sat in the grass listening to the cicadas sing, and enjoyed the rolling hills of Carolina. Even though I enjoyed my break, you bet I’m going back to sea!
Flying solo becomes easier and less nerve racking with every connecting flight. I had a flight delayed by about 6 hours, so I landed in Anchorage, Alaska in the wee hours of the night. I scored a few solid hours of sleep before hopping on the next plane, and finally wound up at my final destination of Nome, Alaska, along with some of my colleagues.
Nome has a local population of around 3,600 people, and was part of the American Gold Rush. People flocked to the area to hunt for the valuable treasure, and gold mining is still relevant in the area today. This sign for Nome pays homage to the gold panning history of the town. The area is often a place of transit for people preparing to board ships, and has a very welcoming and kind community. We were privileged enough to have a full day to explore the area, talk to the locals, and enjoy some of the local businesses.
I met up with one of my mentors, Tyler, my co-intern Kaleigh, and even some of the members of the Coast Guard. We made introductions over dinner and a game of pool at the local pool hall. Check out Tyler’s signature move, which has roughly a 47% success rate!
A rental car allowed us to take in some of the sights on the outside of town as well. Rain and foggy conditions made walking a bit of a chore, so the car was a Godsend. We visited the local visitor center and museum, and everyone recommended we take a drive over the hill. The landscape and environment is so beautiful, and bustling with life. We saw birds of prey such as Osprey, small mammals, and many sea gulls and song birds. Just as we were ready to turn home and call our sightseeing quits, we stumbled upon some Musk Ox, or Ovibos moschatus. You can read a quick article about their conservation efforts here!
Once our tourist activities were over, it was time to embark on our mission; join the US Coast Gaurd Cutter, Healy! The ship was at anchorage, so a small boat shuttled us from the shore. It seemed to be a bit of a daunting ride in the wind and cold, so we donned our mustang suits and hardhats, and held on tightly for the trip. Thanks to the skilled crew, we made it safely to the shipside and climbed the Jacob’s ladder up. Once all personnel was on board, the luggage came shortly after. Everyone and their things made it safely aboard!
The ship itself is massive, by far the largest I have had the pleasure to step aboard. At 420′ long, she is called the most technologically advanced ice breaker, and also the largest vessel within the Coast Guards fleet. The Healy is a beast of a scientific platform, and for good reason! Research in the Arctic is difficult and harsh, which takes the grit and drive of a vessel such as this. Pictured is the back deck, complete with the all familiar A-frame. In the background, Nome slowly fades out of view as we sail out to sea.
As we begin our transit, we earn ourselves a tour of the humongous ship. Our mentor Tyler was also once a MATE intern, and it is very rewarding to see how different life paths can all converge into one outcome. Seeing how someone in my position can proceed in life and succeed in their career instills hope and even more ambition.
So, this begins my journey of sailing on the Healy. Even though I will most definitely still get lost behind a long line of watertight doors, trust that I am somewhere on board trying my best. I am super excited to see how the Coast Guard functions on board a research vessel, and learn how a marine techs skills can assist the science party in their mission amidst the training drills and station bills. Stay tuned for more, and come rescue me from the labyrinth of hallways if you hear yelling coming from the inside of the bilge!
For my final week on the Healy we arrived in Unalaska, better known as Dutch Harbor. It is the largest fishery in the United States by volume of fish caught, as well as the home port for Deadliest Catch. It was also invaded by the Japanese during World War II, with pill boxes and bunkers scattered across the island and its hills and beaches.
Being part of the Aleutian Peninsula, this place is very remote with a population of around 4000 people. This allows for an abundance of wildlife to flourish, including wild horses, seals, whales, ground squirrels, foxes, otters and bald eagles everywhere you look. The weather was decent so I was able to do a short hike and see plenty of these animals up close and personal, with great views of the town and surrounding landscape.
On the Healy side of things we had to close out the cruise as this leg of the season was coming to an end. I got to learn about data transferring and backup, as well as shutting down our sensors while we were in port. After leaving Dutch, I learned about starting a new cruise and was in charge of doing the freshwater flush and flow setup for one of the water walls, as well as cleaning out the filters(being in port allows for a lot more bio-fouling).
This was an invaluable experience and window into life at sea and science research instruments, and I would like to give special thanks to my mentor Howie, as well as Christina, Joe, Maria, PSN Boo, PSN Brian, Captain Serumgard, and the Healy crew.
I hope you had a great 4th of July last weekend–I certainly did, and I’ve got some updates to share!
Starting off strong, I’ve continued to dig into the world of big data science, and I’ve been exploring some tools that other institutions and entities have made for robotics and similar projects. The good news is their solutions are offering guidance on what ours should look like, but the neutral news is that their solutions aren’t going to work for our solution!
I’ve been putting together a presentation to share my research and findings with the rest of the Sentry software team, and I’ll be presenting that this Thursday to receive feedback and input on my proposed architecture design. To give you an idea of the type of thing I am talking about, here is a quick mockup of a possible solution’s architecture.
The other really exciting thing that happened this week isn’t exactly to do with Sentry, but it was inspired by it. Being around big, awesome, deep sea vehicles really gets you inspired. So inspired, in fact, that you may even become the owner of a vehicle yourself–for your own tinkering and scientific experiments of course.
This past weekend I picked up a deep cherry red 1975 Honda CB200 motorcycle.
I drove a moving truck 100 miles, on a 6 hour drive that should have taken me 2 hours, through peak 4th of July traffic to retrieve such a treasure and I’ll say it was completely worth it. Here’s a picture of the motorcycle when I picked it up.
And here are some comparison pictures on my first maintenance project; de-rusting and revitalizing the front suspension forks.
left fork before Right fork after
This small beast definitely has a lot of work left, but no worries because I don’t even know how to drive a motorcycle yet. All in good time!
This week I got to get my hands a bit more dirty and really dive into the mechanics of data science and the data world of robotics.
I’ve been assigned a project which will help Sentry and other AUVs utilize machine learning, deep learning, and other advanced computer thinking techniques.
The problem statement and background is this:
Sentry cruises are structured in that there are a certain number of dives each cruise, anywhere between 5-15 is typical. Between each dive, when the vehicle is pulled shipside there are a number of checks and maintenance tasks performed on the vehicle. During these checks, experts will look over the data that Sentry retains from the dive. There is so much data, but the type that these experts are after is the engineering data and the sensor data. Engineering data reports upon things like thruster performance and battery health during the dive, whereas sensor data is the juicy stuff: it’s what the scientists are after, and what the whole point of the dive is. The thing is, the sensor data is helpful for us engineers as well. Experts can comb over the sensor data and notice if sensors are calibrated incorrectly, or if something is going wrong on a hardware or software level. The engineers then adjust the hardware and software accordingly, and this process happens each dive.
The issue is, some errors are sneaky, and not detectable even to the trained eye until much later in the post processing process, after the cruise has ended. This ends up causing big problems, as it can even render scientific data unusable or “dirty”. So the long term goal of the project I am working on is to automate this process, and be able to catch any errors or data discrepancies in the field, and be able to adjust accordingly so valuable data isn’t lost.
The specific project I am working on to meet that goal is about assembling a machine learning pipeline to automate that process and to even learn new things about the data in the process. The part of the pipeline “under construction” right now is the data staging area. We have tens of terabytes of archived dive data, from just Sentry dives alone. The question is, how do we successfully manage and organize this data, and using what platforms and tools, so that it is optimized to make Sentry a smarter robot? So that the solution is optimized to be used for training and deploying models, that can greatly improve the performance of not just Sentry, but other vehicles in due time.
Anyways, that’s a bit of what I’m working on! Right now it is mostly in the design and planning stages, but like I said, I’m getting my hands “dirty” with a bit of code!
Since my last post, I have concluded my technical internship aboard the R/V Atlantis. Now that I’m back home, I can take some time to update my blog and tell the story of Alvin Dive operations.
Departing Dutch harbor on June 15, we set sail further west along the Aleutian chain.
Pilot boat pacing alongside the Atlantis waiting to pick up the Pilot.
Arriving at our first dive location on the 15th a few miles off Bogoslof island, my job was to arrange the science basket by installing and moving around push cores and bio quivers, attaching Niskins, and securing bio boxes. I would meet with the Alvin Pilots frequently, getting feedback on equipment position and making changes to ensure the instruments were in optimal positions for the robotic arms to access.
Science basket prepared for first dive operation
The morning of the 16th at 5:30am, we started completing the first pre-dive checklists of the expedition. My role as a mechanical technician that morning was to top off all of the compensated volumes on the vehicle. These are oil filled volumes that enclose various critical systems including the main junction boxes, battery contactors, and solenoids. There were 3 main types of oils that I would top off: bray, carnation, and hydraulic. Topping off these volumes included plugging in a portable pump sprayer, with the desired oil, into one of the the fill ports on the vehicle and connecting a drain bottle to the opposite end of the system. I would then lightly pressurize the system, monitoring the fluid entering the drain bottle, ensuring there were no air or waters pockets within the system. This process was repeated for each of the 14 main oil compensated volumes on the port and starboard side of the sub.
Taking a short break from pre-dive tasks to watch this breathtaking sunrise over the Bering Sea.
My morning tasks would vary by day. Sometimes I would polish and inspect the windows while other days I would spend most of the pre-dive making basket adjustments, ensuring all the sample collection devices were arranged how the science team and pilot preferred.
Testing the port side manipulator to ensure all joints are functioning properly.
Next, we would roll the sub out onto the back deck, and install the drop weights. These six weights are the main form of major buoyancy adjustment. All six attached allows the sub to descend fast, release two weights to achieve neutral buoyancy, and release an additional two weights to ascend to the surface. The last two weights are reserved to allow additional weight loss, in case extra buoyancy is needed to resurface. These weights are installed using specially designed hand carts that lift them using a hand-crank style forklift mechanism.
Installing steel drop weights alongside Alvin Mechanical Technician, Wren Sakai.
Deploying The Submersible
After all pre-dive checks are completed and signed off, the sub is attached to the LARS (launch and recovery system). The sub is attached to the LARS by several points: a tail line to prevent rotation, a main line wrapped around a titanium T-shaped lifting point, and a large hook that actuates downwards, locking into the lifting T. The pilot and scientific observers enter the submersible, and the hatch is sealed. Two divers are positioned on top of the submersible, and the vehicle is lifted off the deck of the ship. Once the vehicle is over the water, the main line is tightened, allowing the hook to release the vehicle. The main line then lowers the vehicle into the water. Once the sub is floating, the swimmers detach the main line and the tail line, allowing the sub to drift away from the ship. After some final checks, the basket support lines are removed, and the sub is ready to dive. The work boat picks up the swimmers, and the sub floods its ballast tanks, allowing the vehicle to begin sinking.
LARS moving into position to be hooked up to the Alvin sub.
Recovery Operations
After the science dive, we would stage the deck for recovery one hour before the sub surfaced. This included ensuring the tow line was ready to be deployed, and laying out various tools such as drills used to loosen the subs panels and drain bottles for fluid inspection.
The recovery would begin by first lowering the work boat into the water off the side of the ship. The work boat then cruises ahead of the ship to meet the Alvin sub as it surfaced. The boat drops off two swimmers who prepare the vehicle for recovery. When the vehicle is ready to be picked up, one swimmer stays on the sub while the other swimmer boards the work boat. The boat drives back to the ship and positions itself behind the Atlantis, as the ship slowly approaches the sub. We then lower the rear lifelines and prepare to throw the tow line to the work boat. Passing the tow line to the work boat was sometimes my role during the recovery. Once the sub was halfway past the ship, I would toss the heavy rope and floating hook to the work boat. The heavy rope attached to the center-back of the ship would pay out line, and I would monitor the amount of line remaining while communicating with the recovery coordinator. The work boat then intercepts the submersible as the tow line swimmer dives off the work boat, attaching the tow line to the back of the sub. The swimmers then deploy a sea anchor, a sort of underwater parachute secured to the submersible. This allows the sub to be held in tension behind the ship as it is reeled in like a big fish. Once the sub is directly behind the ship, the tail line is lowered and attached to the sub, soon followed by the main line. The sub can then be lifted out of the water and the swimmers dive off the side of the sub to be recovered by the work boat.
Swimmers diving off Alvin as it’s lifted from the water.
One of my frequent jobs was to remove the tow line from the back of the sub after it had been lifted over the deck and as it was being lowered. I would then immediately move into post dive tasks.
One of the Alvin technicians, Scott, removing the tow line as the sub is being lifted onto the deck
Post Dive
Once the sub landed on deck, the Alvin team and I would move in with pins to secure any remaining weights, install life lines, rinse down the sub with fresh water, and place protective covers over the windows.
Me rinsing down the windows and cameras post dive.
The work boat being lifted out of the water right after recovery.
During the majority of post dives, I would sit beside the sub right after it landed on deck and check every oil volume for traces of water intrusion. I would plug a waste bottle into 19 different oil volume drain lines, one at a time, and inspect for water or abnormalities. During this time, the scientists and pilot climb out of the sub and are welcomed by an applaud from the crew and science team. We then roll the sub back into the hanger and finish an extensive list of post-dive inspections and tasks. My usual job was working the scientists. I assisted in removing various equipment and samples from the basket, so the scientists can begin their analysis and packaging of specimens.
My perspective of checking compensated volumes for water.
This formed the pattern that most days followed with the occasional excitement where I would be asked to repair or inspect components that had failed during the dive. These tasks meant anything from reinstalling damaged mounting brackets on the science basket to disassembling and re-compensating large brushless thruster and hydraulic motors.
One of the large brushless motors partially disassembled and filled with WD40 to drive out any possible moisture.
The 18 day science expedition proved to be a big success! Despite several dive days being canceled due to weather conditions, we were still able to accomplish nearly all of the 13 dives we set out to complete.
Keep an eye out for one more blog update describing the post cruise activities including preparing the Alvin for its next few months of rest and even the non-work related adventures I was able to go on while in Alaska.