I am an upcoming intern onboard the RV Thomas G. Thompson as it transits from Suva, Fiji to Noumea, New Caledonia along the Matthew-Hunter Trench. The research cruise will spend a month study the ongoing subduction initiation processes occurring within the region.
I am a Colorado native who loves both the mountains and the ocean. I moved out east for a bachelors degree in Earth Science (Oceanography) from the University of New Hampshire. During my undergraduate studies, I also completed a minor in marine biology during a semester at James Cook University in Australia, as well as a minor in Ocean Engineering.
Outside of the classroom, I was on the club sailing team at UNH and spent many summers as a boat driver on Catalina Island. I am a big enjoyer of nature, music, and food—follow along for a peak into meals onboard a research cruise!
I’m looking forward to sharing more about this journey, the science onboard, and the experience of working at sea in the South Pacific!
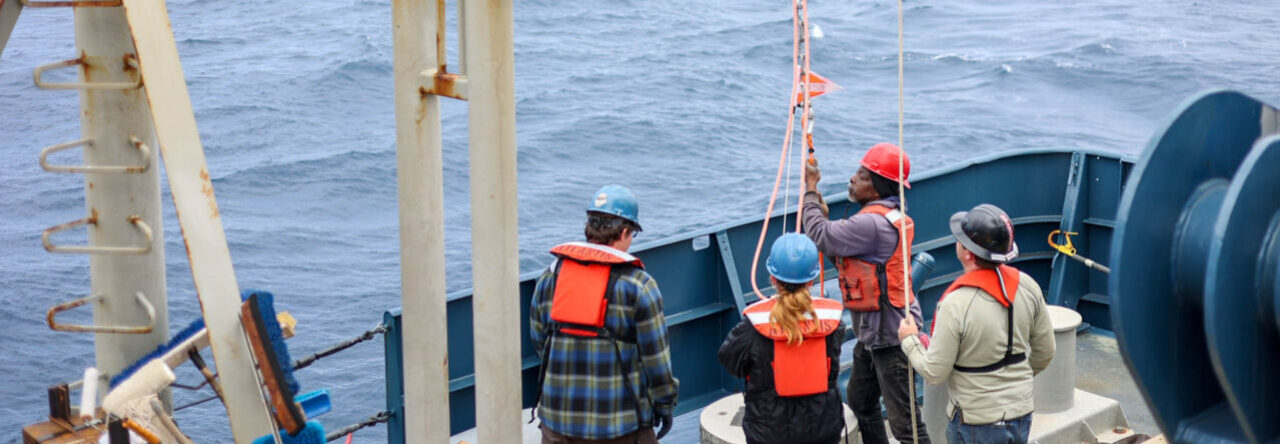
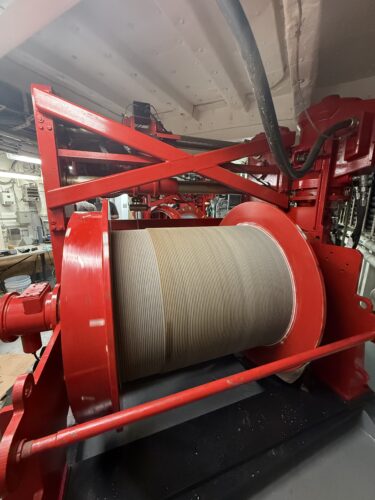
Week two onboard R/V Sikuliaq has primarily featured maintenance on the advanced system of winches. R/V Sikuliaq has an oceanographic traction winch system and two hydrographic winches to support a wide variety of scientific research expeditions. Winch systems play a critical role in oceanographic research. They are responsible for suspending heavy equipment from the ship into the depths, often carrying data directly to the laboratories onboard. This week, we unspooled the winch wires for re-lubrication and maintenance. This required a spooling system on the dock to take up slack and communicate with the winch system onboard. To prevent damage to the wires and to ensure proper wire spooling in the winch drum, tension was kept between the onshore spooling device and the ship’s winches. The many moving parts of this operation required direct and clear communication. If the onshore spooling device continued to run while the onboard winch stopped, the wire could snap. Our team was able to successfully lubricate our winch systems, ensuring proper functionality during upcoming research cruises.
We additionally checked the integrity of the wire insulation using a megohmeter. This test applied a high voltage to the winch wire to measure the amount of leakage coming through the wire’s insulation. We tested both the winch wire and the slipring that connects the rotating winch drum to the data cable leading to the ship’s laboratories.
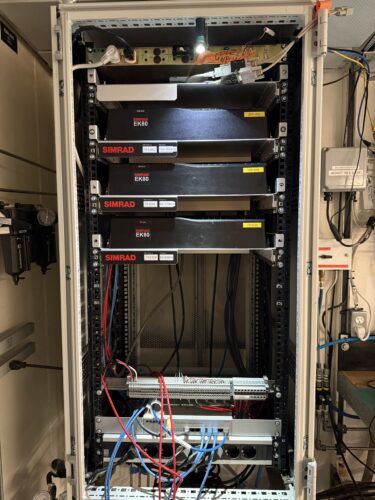
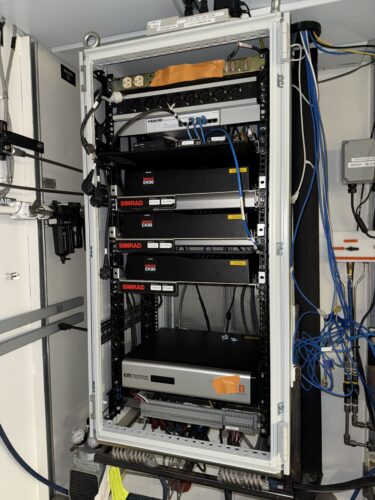
One of my additional projects this week was rearranging the aft mainlab LAN (local area network) rack.
This rack houses the EK80 sonar system transceivers, shown in black. These devices transmit and receive information from the transducers located in the centerboard shoe. To rearrange this rack, I removed the transceivers, power strip, and din rail. I reinstalled the equipment with a more streamlined approach to improve equipment accessibility. Additionally, I installed a new drawer for the Raspberry Pi computers housed in this rack. This quired CAD drawing and 3D printing of a component to secure the shelf to the LAN rack.
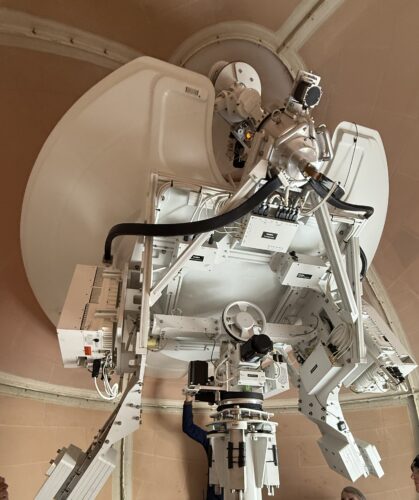
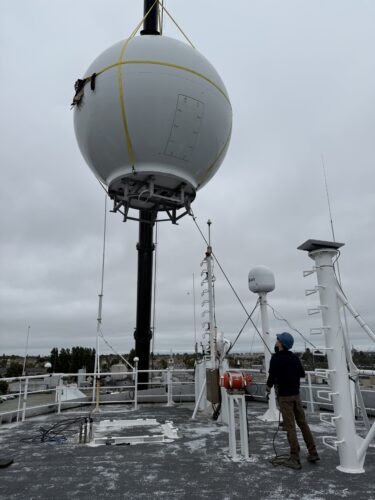
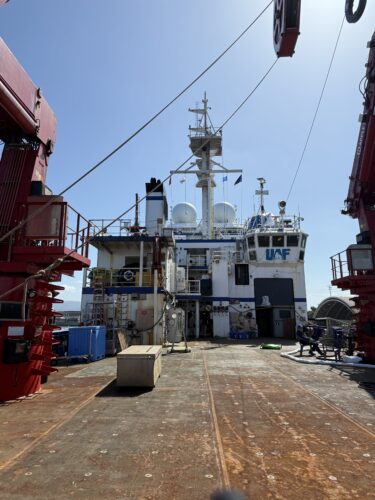
Lastly, we removed the domes! The domes formerly housed a HighSeasNet satellite communication dish. The ship is moving to a OneWeb system, utilizing a low earth orbit (LEO) satellite constellation for our redundant global internet access system.
Connecting how systems send and receive messages has been a critical learning component of this week. I have found it very interesting to see how the software interface operated at sea interacts and connects to the physical sensor units we are servicing at drydock.
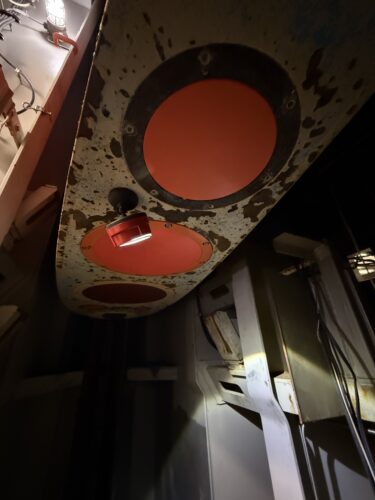
I have completed my first week onboard R/V Sikuliaq as a MATE intern! Getting an introduction to the vast array of scientific equipment onboard has been an incredible first-week experience. One of my favorite things to learn about R/V Sikuliaq is how her equipment is specialized to face harsh, icy conditions in the Arctic and the Antarctic. We are currently docked in Oakland, California. This week was all hands on deck, preparing the ship to be lifted out of the water. One of our major projects was the removal of the EK80 sonar system transducers from the centerboard shoe. The centerboard is a large retractable structure within the hull of R/V Sikuliaq that houses sensitive sonar equipment. The centerboard extends beneath the hull when the equipment is in use, gathering high-quality seafloor mapping and acoustic data. When the instruments are not in use, and particularly when the research vessel is facing icy seas, the centerboard retracts within the hull. The centerboard shoe is the housing at the bottom of the centerboard that holds the transducers.
Working inside the centerboard shaft is a very unique experience. The centerboard shaft almost resembles an elevator shaft. A metal grate is placed in the area beneath the retracted centerboard. The ocean lies beneath the grate, with the centerboard looming overhead. It is not a place to fear heights or confined spaces. We were able to successfully remove the transducers, requiring very careful use of tools to pry the instruments from their seats. The face of the transducers is very sensitive and has to be handled with extreme care.
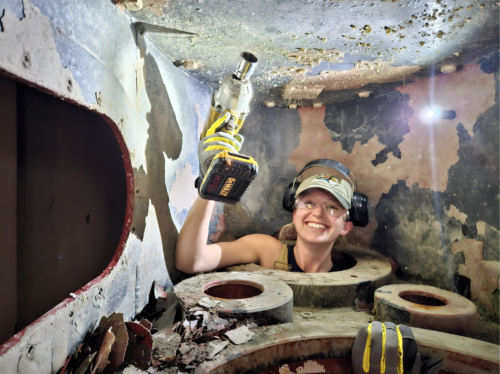
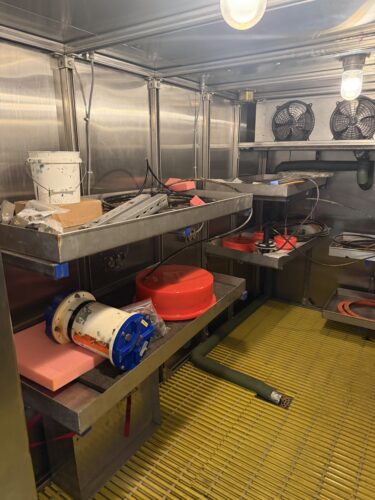
Above is a photo of me inside the centerboard shoe after the removal of the EK-80 transducers. The space is very small, but I feel right at home! Below is a photo of the removed sensors, stored in an unused refrigerator.
Other smaller projects included designing and printing new caps for the upward and downward facing sky temperature and sea surface temperature sensors, climbing to the top mast to inspect the meteorological equipment, studying how instruments communicate throughout the ship, and exploring Alameda Island. It has been a great first week with the crew!
For the final week of this internship (May 1-9) we finalized our pending tasks of installing all the new phone lines in the portable labs along with several internet access points and a few more SOFAR Buoy deployments.
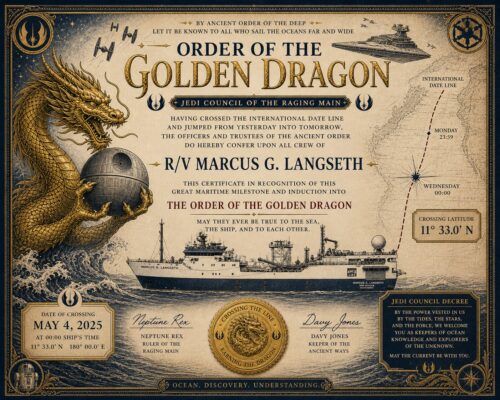
Before that however, we crossed the anti-meridian and successfully completed the “Order of the Golden Dragon” sailor’s merit, which just so happened to occur on May 4th and inspired Cody to create a commemorative print out (with some minor adjustments).
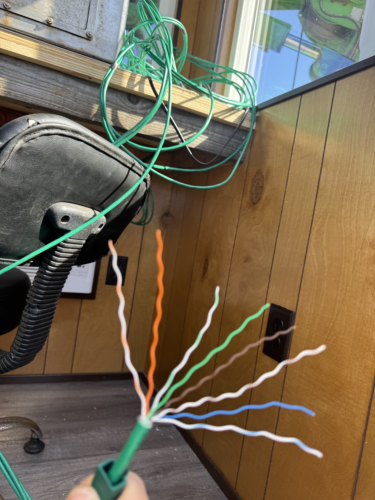
The first part of this task included setting out 6 sets of CAT5e cables, each measuring approximately 15 fathoms of length. After setting these cables and terminating both ends, we fed the lines into our port lab switch box before inserting 2 cables into each of the DICE portable lab transits.
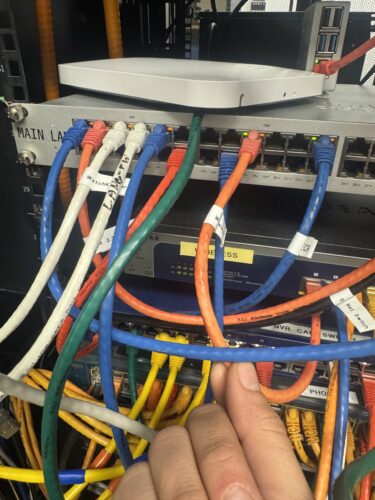
After troubleshooting a faulty port in the main lab server rack, all lines responded well to our internet access point modems and phones which lead us to wrap up our work and close the transit. For our remaining work, we assessed a previous gravity tie and land tie in order to determine our delat and rate of change between previous readings, which as metadata could be used to determine if e would need to have the gravimeter recalibrated soon. We also had enough time before reaching Majuro to set up another CAT5e cable in a POE termination pattern for the aft IFR camera, which will serve as a useful tool for supervising seismic gun operations and ensuring no sealife are around high risk sections. Finally, I also had the opportunity to practice XBT launches, which will add a new incredibly relevant skill to my professional summary.
–Arriving to MAJ–
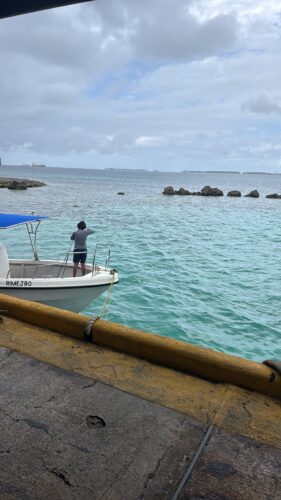
We arrived to Majuro a short while after finishing our work, and I was able to spend some time ashore speaking with the incoming technicians and science team, in fact, Theo (previous MATE intern and current field scientist aboard the R/V Langseth) and I got to meet up and talk about how much this program has changed our careers.
–Final Thoughts–
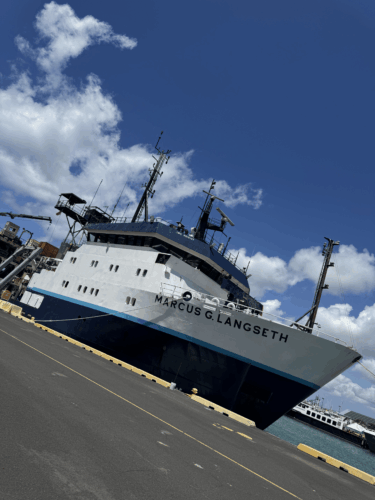
As this program comes to a close, I want to thank the R/V Marcus G. Langseth’s crew for being so welcoming, and I especially would like to thank Jacob Greenberg and Cody Bahlau’s tremendous guidance throughout this program. The UNOLS-MATE program has made me a much more confident scientist, oceanographer, and maritime technician, and will surely lead me to a successful career in the near future, for now however I say farewell and hope to have even more stories to tell some day, whether online or in person when we recognize each other in a remote part of the world.
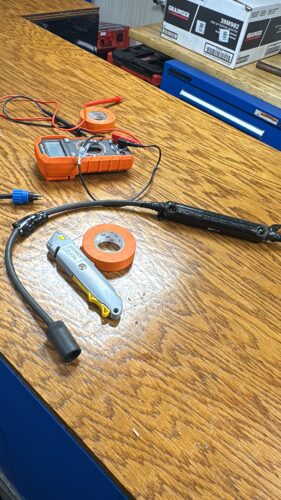
During the second week of this expedition to Majuro (April 24-30) we were able to successfully reterminate the CTD sea cable and through doing so solved the persistent shorting problem we had noticed during the end of the first transit week.
As such we immediately began testing and re-assessing the communication between the deck box and CTD, which we found to be nominal. To add to the excitement we also crossed the Tropic of Cancer a few hours after, marking our approach to the islands of Hawaii. As our next objective we began fixing and preparing the ship’s deck equipment for future use, such as attaching metal fasteners to allow our extension poles to hold boat hooks.
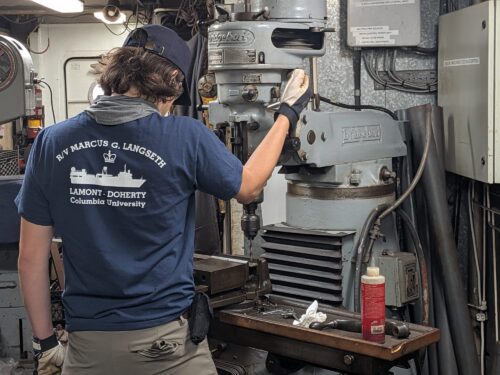
By drilling pilot holes using the ship’s mill press, we were able to bolt the fasteners and poles together at a point that would allow them to reach their maximum height. Shortly after, we began preparing for our arrival in Honolulu by further securing sensitive cargo such our CTD with a tarp and cleaning our major workspaces such as the “gun shack”, “tech shack”, main lab, wet lab, dry lab and our metal shop.
Taking advantage of the bit of downtime we had available before having to shut down our sonar systems, I had the opportunity to practice splice knots and learn how to terminate CAT5 cables. In the last few hours of our approach to Honolulu we shut down our major sonar systems and did our final set of checks before shutting off analytical systems such as the pCO2 system in port, and had the great opportunity of exploring some of the island before our departure the next day. I took the opportunity to visit sites like Pearl Harbor, Waikiki beach, and the site of Sailor Jerry’s original tattoo shop where he developed the modern americana style of sailor tattoos.
–Underway from Honolulu—
The next morning we began making our way out of port and headed out for Majuro, as our first priority, my mentor Cody Bahlau and I began talking about the objectives we would be working on during the transit to Majuro which varied from terminating new cabling to installing a new FLR camera on the OBS deck.
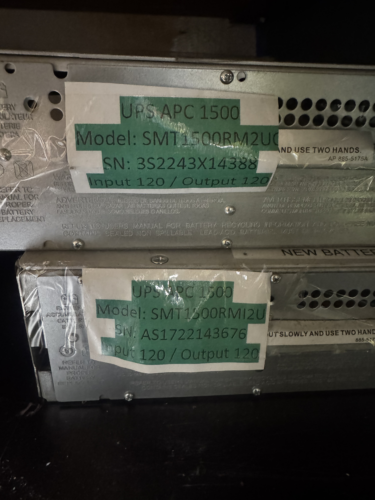
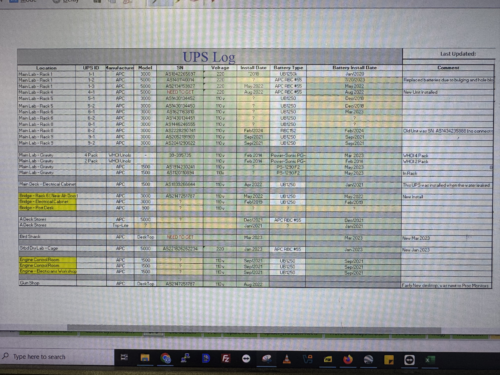
Taking advantage of our initially calm waters we decided to start by fully inventorying and organizing our APC battery supplies, we also updated our logs to identify if any batteries in use were due to be swapped from the ship’s power. Further on we launched the first SoFar buoy/sensor of the transit and had our weekly check in with the rest of the tech team to review our current goals, ongoing projects, and a review of any pending questions or issues.
The next day we wrapped up the week by reterminating our remaining CAT5e and CAT6 cables along with setting up the working directories for interdepartmental phones that will be installed inside the portable scientific workspaces found throughout the ship.
Our work continues on the ship and weather has remained calm on our departure from Hawaii, although it has begun taking a turn for choppier waves.
I’m excited that we continue to approach the antimeridian and will successfully cross it during the last set of days in our journey, completing the sailor’s achievement of “Domain of the Golden Dragon”. Sadly we will be crossing just 2 degrees north from the equator and won’t complete the “Golden Shellback” achievement. This internship has been a tremendous aid in sharpening my skills and further understanding a marine technician’s role aboard oceanographic research vessels, and I greatly thank everyone who has been a part of supporting and mentoring my journey!
My name is Paige FitzPatrick, and I am the new UNOLS-MATE intern onboard R/V Sikuliaq! I will be training with the team of marine technicians during the upcoming drydock period.
I love creative problem-solving and am very interested in fabrication in marine science. I learned seamanship skills as a scuba instructor before studying a degree in Marine Affairs at the Rosenstiel School of Marine, Atmospheric, and Earth Sciences (RSMAES) with the University of Miami. In my time at RSMAES, I developed a passion for 3D printing, marine research, and vessel operations. I completed my undergraduate degree studying Marine Affairs both onshore and at sea with the crew of R/V F.G. Walton Smith, training in marine technology and shipboard engineering. I earned my 100-ton USCG Captain’s License and QMED Marine Engineering License in this position. I was able to research 3D printing applied to subsea instrumentation with the Makers Marine Technology Fabrication Laboratory, further inspiring my passion for this field. I am always excited to better my seamanship skills and expand my knowledge.
You will most likely find me on my paddleboard outside of work. I love photography and being on the water, ideally with a pair of binoculars for spotting cool birds. I am so excited to be training with the incredible team onboard R/V Sikuliaq and am grateful for the opportunity to join the MATE internship! This program will help me take the next steps in achieving my goal of becoming a seagoing marine technician.
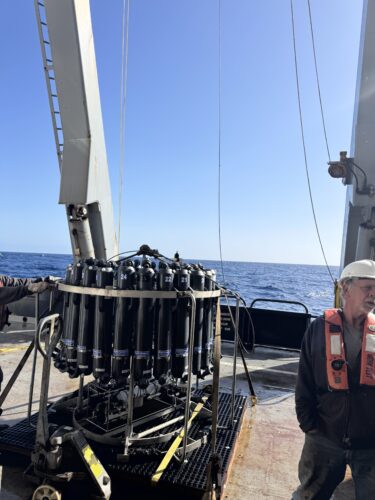
Over the course of this last week (April 15-23), I’ve had the great pleasure of assisting in the R/V Marcus G. Langseth‘s procedures for getting underway and initiating its essential scientific systems. Two days before leaving port I arrived on the ship to begin loading and securing outgoing scientific gear destined for other UNOLS facilities such as the UH Marine Center in Honolulu. Additionally, we began stowing the mission critical equipment that we would later be testing, maintaining, and in some cases deploying. As such I began familiarizing myself with the ships laboratories and main deck spaces that we would be using over the next few weeks to deploy SOFAR buoys along with both “Deep” and “Core” variation of Argo Floats. A-Frame calibration checks were done to ensure accurate tension readings from the winch system and in order to begin preparing it for our use in future CTD/ rosette carrousel deployments. In our last day before leaving San Diego, we secured our remaining scientific equipment through the use of unistrut eye-bolts and ratchet straps before reviewing key documents related to the ship’s systems such as its coaxial camera to video system infrastructure.
—Underway from SD —
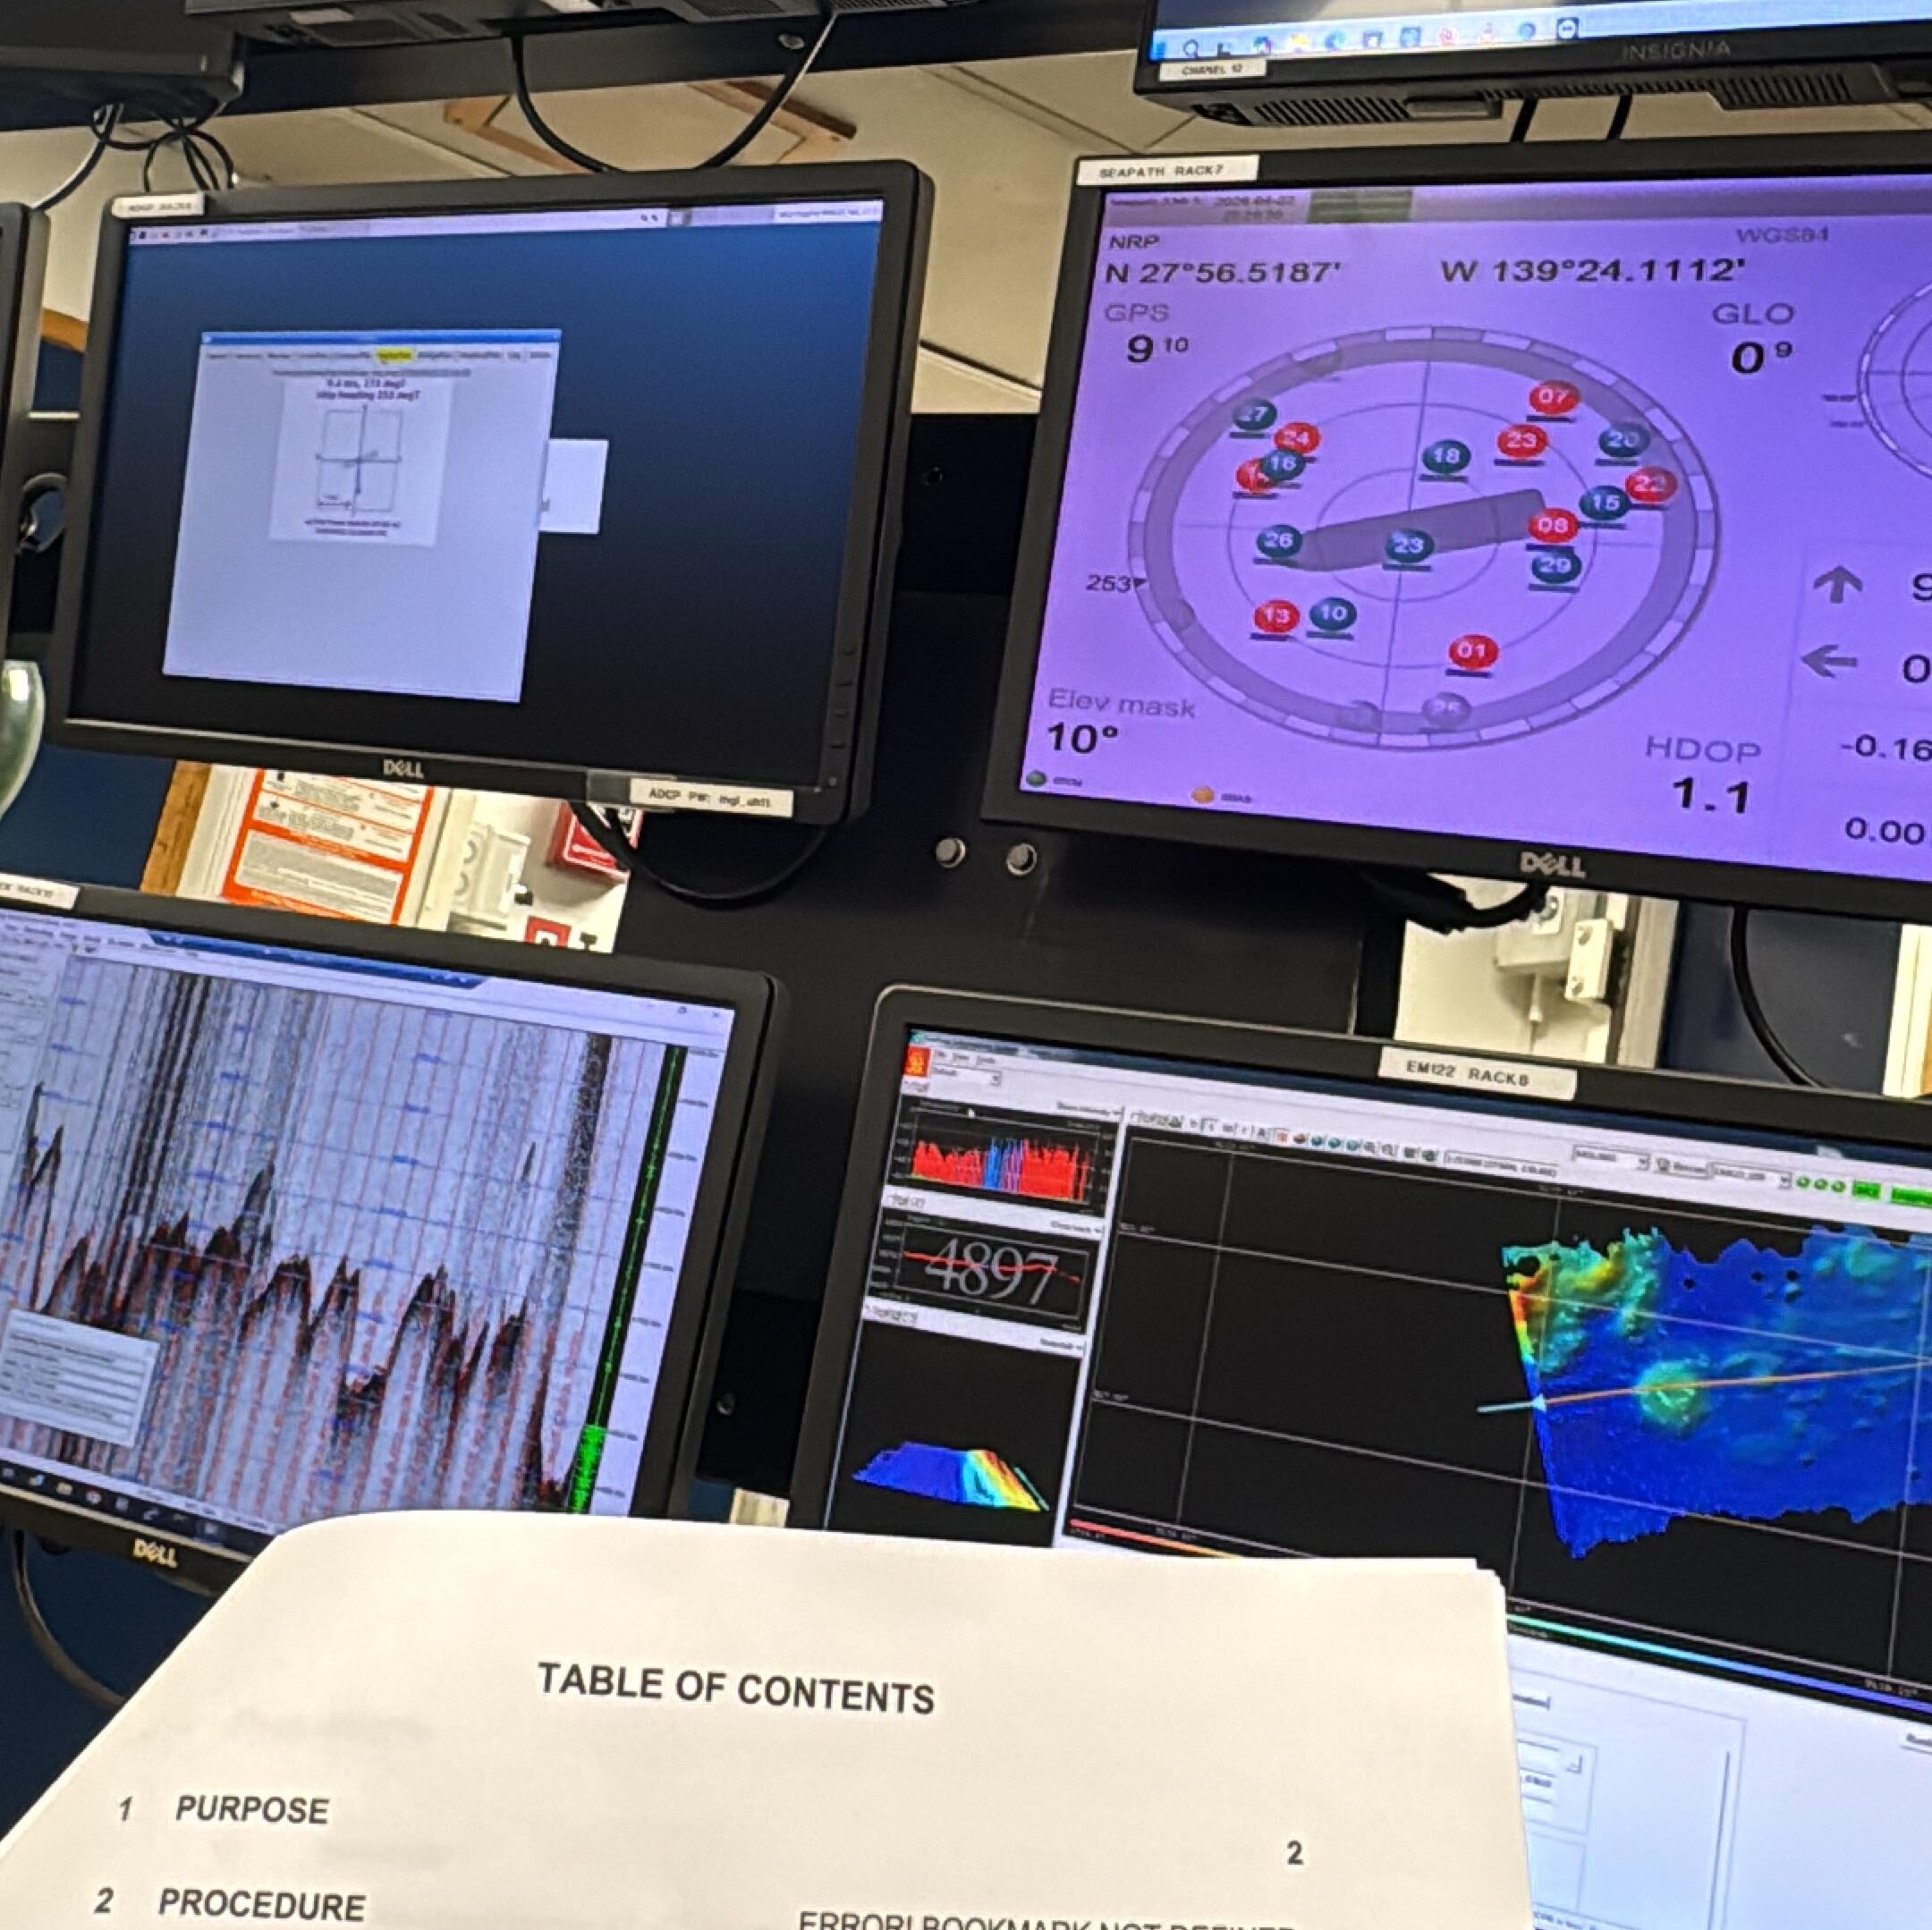
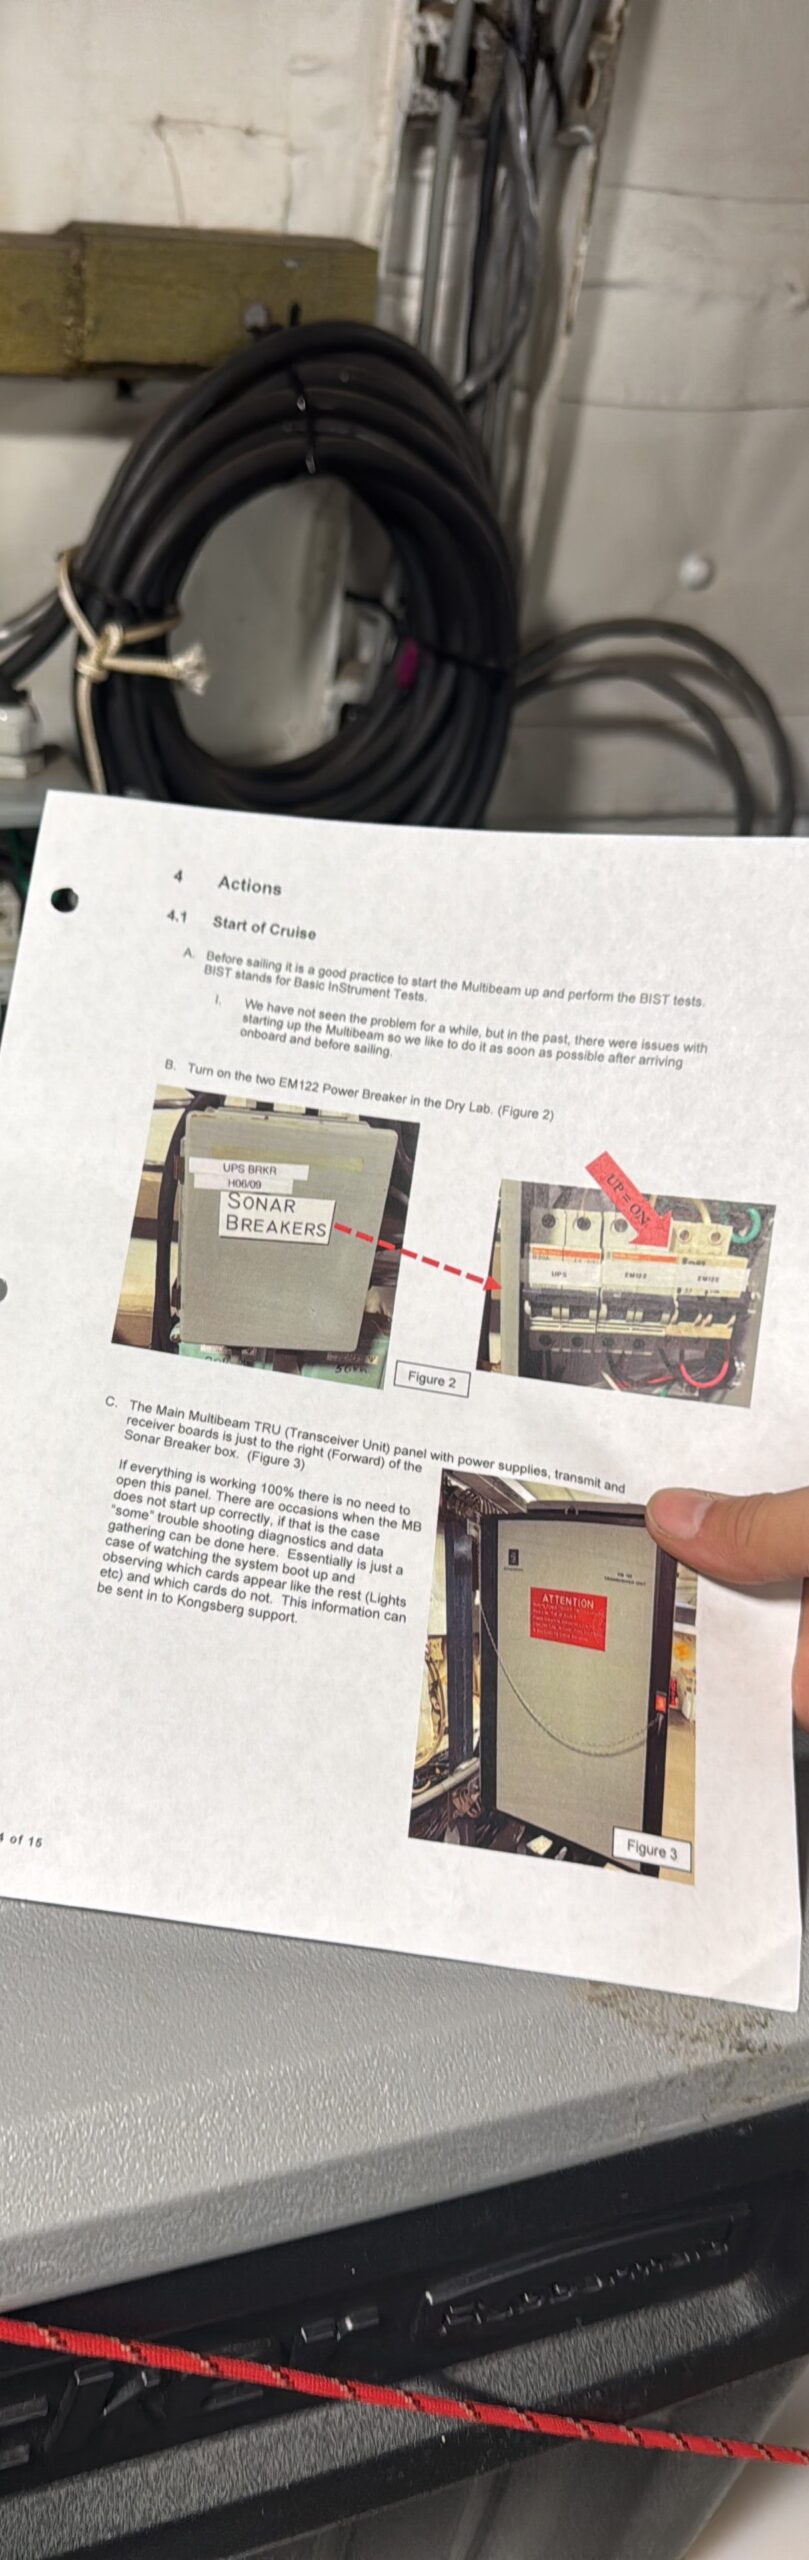
This first week of the transit from san Diego to Honolulu has been highly demanding and busy, we began the week with securing miscellaneous equipment while beginning our transit out of the bay and into deeper waters. Throughout this time we took advantage of the calm waves to add fixtures in both the ship’s wet-lab and dry-lab that would ensure better access and protection to the science team’s equipment, especially considering our expectation of encountering rough weather within the next few days. Once out of the coast, we began powering the ship’s multi-beam echosounder (an EM122 by Kongsberg), ‘CHRP’ ADCP (3260 Echosounder by Knudsen) and SeaBird SBE systems. Shortly after, we noticed incongruencies on the live data between the ADCP and echosounder’s depth readings and began early troubleshooting efforts which were finalized by that afternoon.
The next two days were spent focusing on deploying and testing our CTD system, during the morning deployment all systems worked nominally until we reached 100m, at which point we stopped receiving data but still held a firm connection between the deckbox and CTD module. As such the rest of the day was spent troubleshooting the system and having a post-launch debrief on our next steps.
Later on we would find that the CTD’s deckbox to sea cable fuse had blown and as such began testing the sea cable’s wiring in an effort to locate a possible short, this would later lead to us tracing the short to the terminations between the seacable and CTD plug.
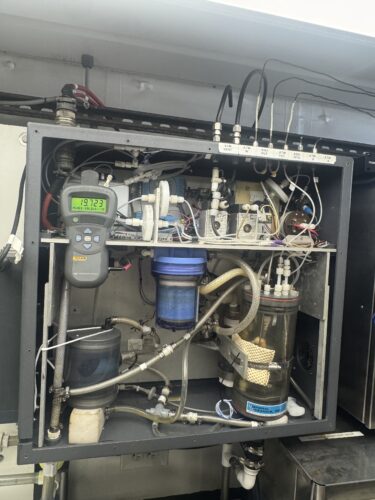
During the next day we deployed our first SOFAR buoy at 5am and as part of our daily checks ensured that the temperatures of our sample-housing refrigerator units remained nominal. As part of an ongoing project to improve the infrastructure of our pCO2 measuring system we also began mounting a dedicated bracket for it’s dedicated power station, that same afternoon we would also begin a lengthy process to activate and at times de-airlock this delicate gas-mixture dependent piece of equipment.
The remainder of the week would be characterized by troubleshooting some of the ship’s server room computers which had lost their remote-connection capabilities due to power lapses, along with launching two more SOFAR buoys, an Argo “Core” float and an argo “Deep” float.
Our work continues on the ship and weather has calmed extensively, dropping our previous roll of nearly 5.2 degrees and heave of 5m to a 1 degree roll and 0.5m heave. Conditions continue to improve with our approach into tropical waters and the next log will be marked by us crossing the Tropic of Cancer. I am extremely glad to have this opportunity of assisting on board and greatly look forward to the next few weeks!
Ahoy there and good timezones! My name is Conrado Acevedo Batiz and I am a new intern aboard the R/V Marcus G. Langseth for the UNOLS-MATE program. I am an oceanographer and seafarer with a passion for exploration and expeditionary research, as of right now my goals are to become a maritime technician for oceanographic research vessels and I hope to one day become an ROV and submersible technician/pilot. I’m incredibly grateful for this internship opportunity and look forward to spending a month at sea learning from the highly skilled technicians and crew that make the RV Langseth such a valuable asset to ocean exploration and research. Cheers and pleasure to meet you!
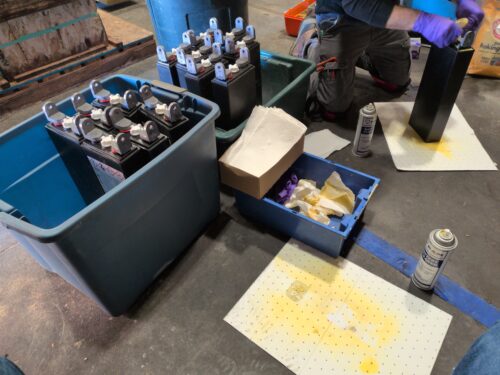
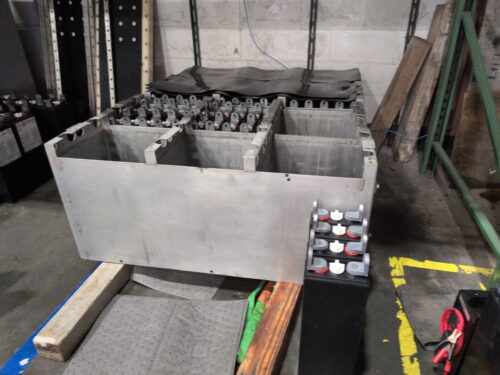
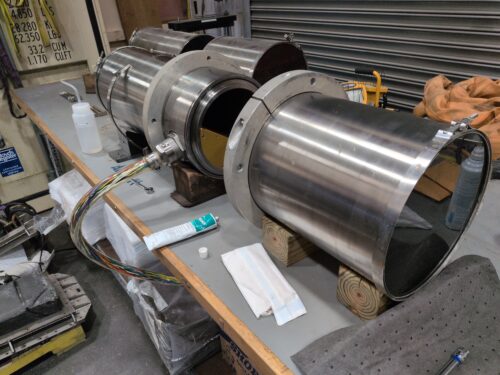
The main batteries were the centerpiece of this week. These are the large lead-acid battery packs that power Alvin during a dive, and it was time to replace the individual cells. Each battery is constructed of 60 cells in two trays, top and bottom, with two batteries installed at a time. Generally one is dedicated to powering port side equipment and one to starboard. Each cell is roughly 2 volts, for a total of 120 volts DC for the high power devices, stepped down by the power bottles to various lower voltages for everything else. There is a third battery and a consistent rotation of the three, so that while two are in service the third is going through regular preventative maintenance.
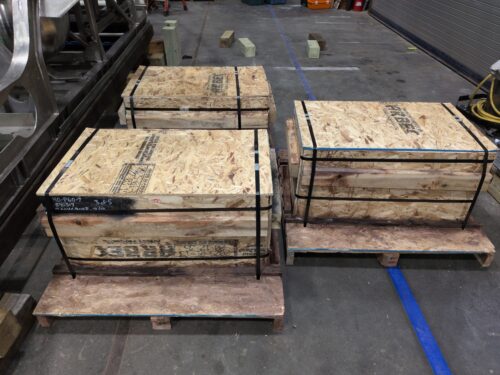
To cover replacing each cell across all three batteries, five pallets totaling 200 new cells were ordered, 60 cells per battery with 20 spares to cover the multiple years they will be in service, ensuring the cells will always be of the same construction and age. With each cell being of similar weight to a car battery, there was a lot of manual labor involved.
The first stretch of the week, Monday through Wednesday, was spent on the swap. The old cells were pulled from the trays a small quantity at a time while a similar amount of new ones were pulled from the shipping pallets and cleaned before installation. The used cells were stored back in the shipping pallets for later return, and the new cells were inserted into the trays.
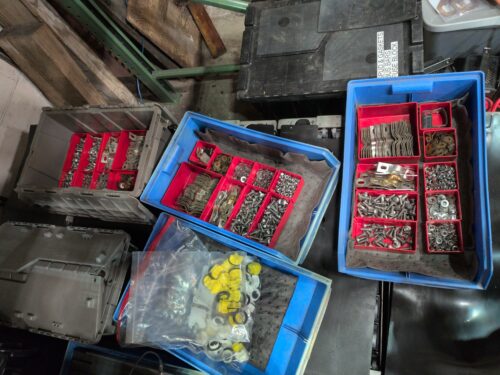
The new cells are a slightly different height than the old ones, which meant new spacer plates that sit beneath them and protect the cell bottoms needed to be fabricated to bring the terminals to the correct height. And in preparation for the future work of connecting all the cells together, the terminal connection hardware was cleaned with degreaser and run through the sonic cleaner, then sorted and set aside for later installation.
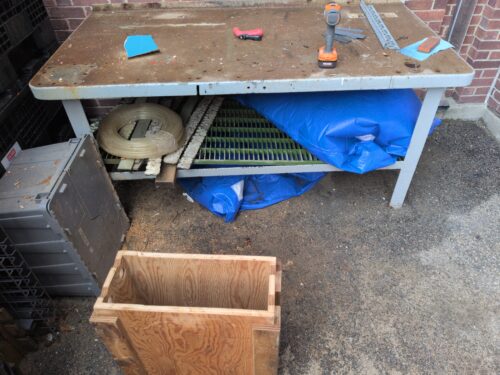
With the trays fully populated, Thursday shifted elsewhere. The spare cell storage boxes were modified to make it easier to store and remove spare cells. And work began on sealing up the pallets of old cells for shipment.
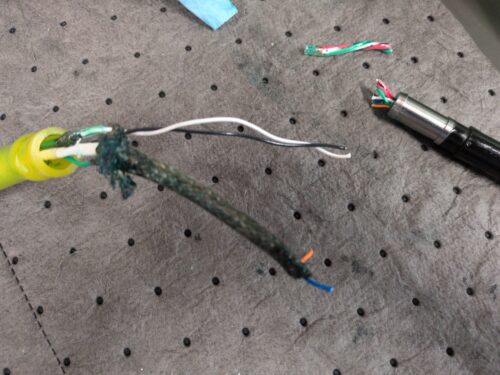
Friday was a mix of tasks. A pair of camera PBOF cables needed shortening to remove damaged sections, with the connectors replaced in the process. The rest of the day went toward finishing up the used cell pallets and getting them secured. Once sealed, the pallets were moved out to clear space in the shop for the following week, when a specialized metrology company was arriving to create a precision 3D scan of the sphere.
Week 17:
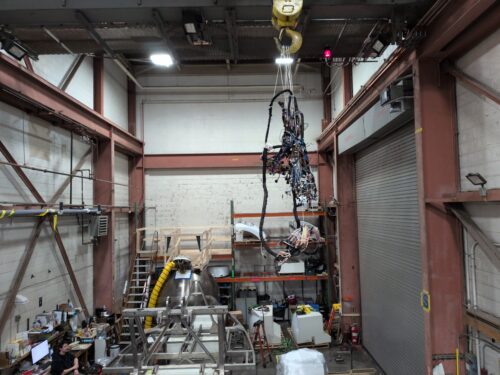
Monday started with installing the I&I bottle housings back into the forward section of the frame. And the sphere wiring harness was craned back to the sphere. Rick is leading the task of re-installing the equipment and harness into the sphere.
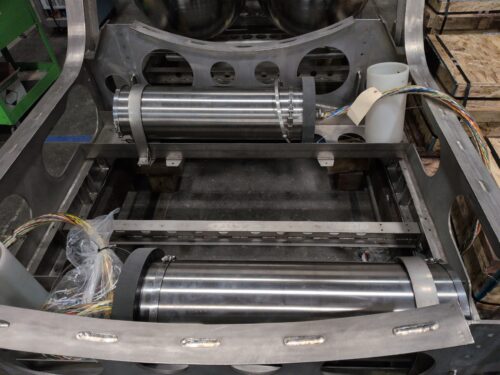
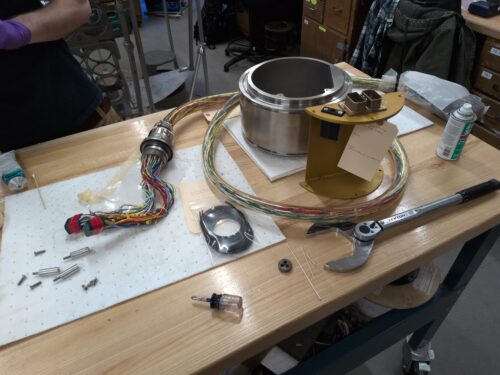
On Tuesday, some minor alterations were made to cables running to various junction boxes. And I joined Scott to begin reassembly of the power bottles. The power bottles consist of a high power side and a lower power side, joined by a middle ring that contains further connections.
Power bottle reassembly continued through Wednesday.
Thursday was spent on the re-installation of the aft bottle rack, which houses the power and data bottles. It needed a cleanup, and several holes were enlarged to better accept the threaded rod that bolts the rack assembly together.
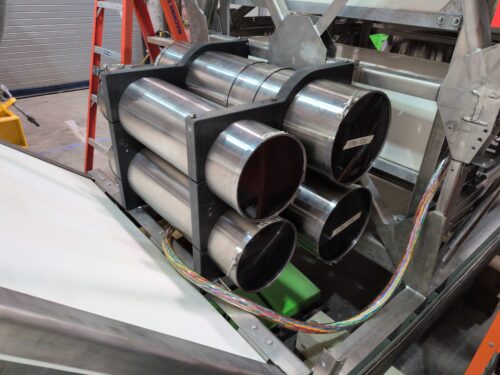
The week wrapped up Friday with finishing the installation of the aft bottle rack and populating the power and data bottle housings into the frame.
This one is short. A significant blizzard moved through the region and shut down WHOI campuses for the first four days of the week. Roads were closed to unnecessary travel and many of us were without power for days. It was certainly an interesting time, though some of us did fit in some sledding and board games.
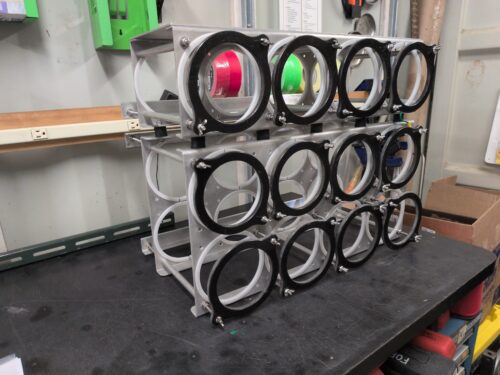
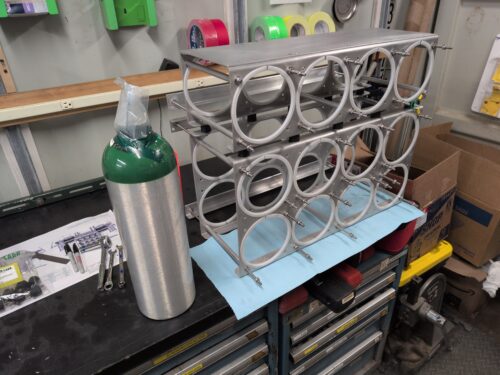
Fortunately, the crews working to clean up after the storm and restore services had things back in order by late Thursday, and work resumed Friday. I picked back up on the oxygen rack cleanup where it had been left off. And helped the mechs remount the skids to the bottom of the frame. These protect the extremely expensive titanium frame by taking the brunt of the damage caused by Alvin resting on rough surfaces like concrete, rocky seafloor, and the ship deck.
Week 15:
The oxygen rack cleanup wrapped up Monday, bringing that project to a clean close.
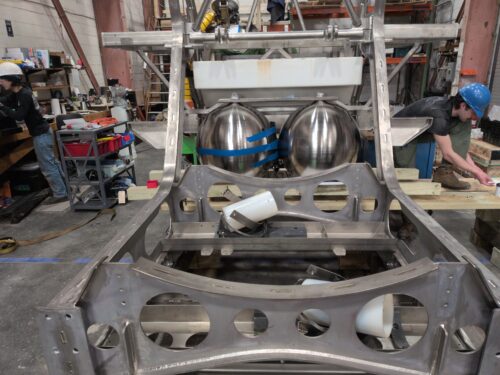
Tuesday brought continued work with the mechanical side of things. I helped the mech team reinstall the forward variable ballast spheres, the same titanium spheres that were cleaned and borescoped previously, now making their way back into the vehicle as reassembly builds momentum.
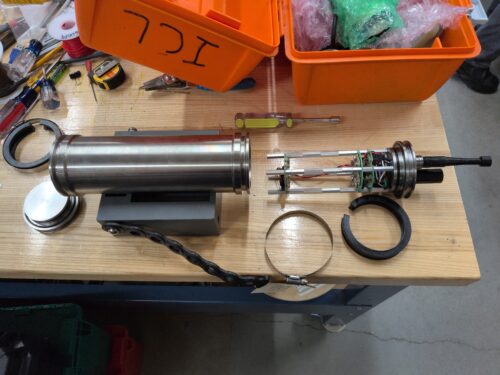
On Wednesday we were testing the Inductively Coupled Links (ICLs) after they had been loaned out for a non-Alvin cruise. ICLs use inductive coupling to create a very short range wireless communications link between temperature probes and Alvin, allowing collection of seawater temperature data without each probe being wired directly to the vehicle. This allows multiple temperature probes to be mounted on the science platform with only one required wired connection into Alvin, as the manipulator arm can move the reading device between whichever probe is needed. Testing included the usual visual inspections, probe calibration checks, and verifying the expected data over the serial link. One faulty ICL was found but repaired easily, as it was simply a failed solder joint on a wire-to-board connection.
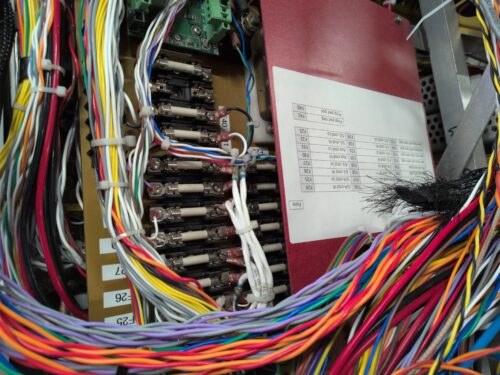
The rest of Wednesday was spent back in the birdcage, continuing the AV wiring work, along with a few control system wires, and some improvements to component labeling.
Thursday I remained in the birdcage, finally completing the wiring work. Sadly I didn’t manage to get any pictures of the finished AV wiring. You’ll just have to believe me that it looked very clean, as the birdcage began disassembly soon after for re-installation of the wiring harness and equipment back into the sphere.
The week ended a day early for me, as my Friday was spent in bed sick.
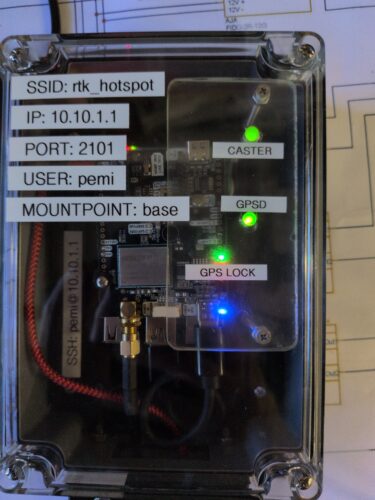
Over the weekend I finished a school project that I had been working on over many weekends this semester. A mobile GPS base station that provides RTK correction data to an aerial drone, giving it more precise positioning than the drone’s onboard GPS receiver alone. The tough part was building it to operate as a standalone system in remote regions with no cell service or internet connection. Made easier by the control of configuration provided by device using open source software and mostly open source hardware.