Category: Woods Hole Oceanographic Institution Page 7 of 16

Week 3 R/V Neil Armstrong: Wrangling Buoys!

One of the mates took this photo from the bridge (I’m wearing the puffy jacket)! Source: Lia (Third Mate)

09/07/23 – 09/14/23

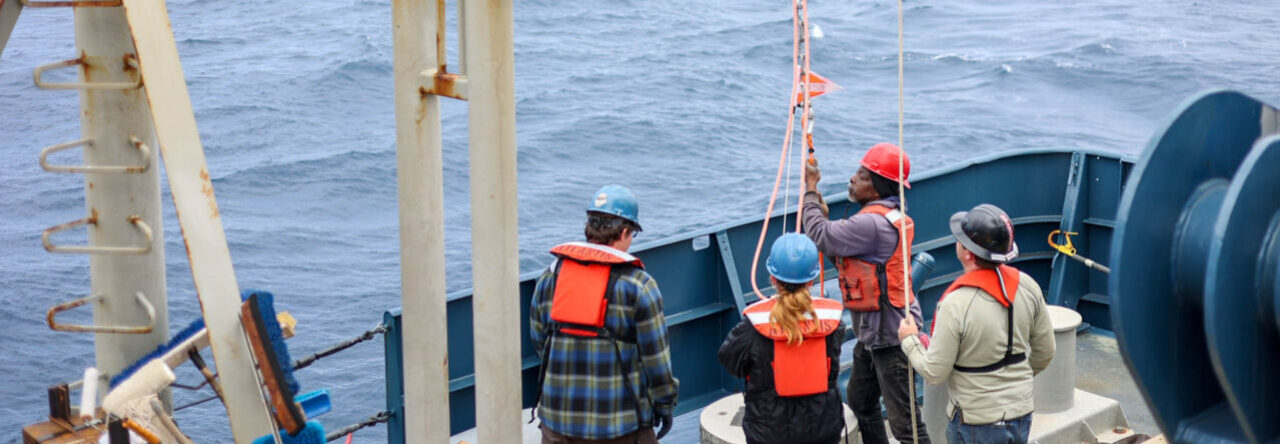
We are currently transiting back to Woods Hole! This week, we wrapped up the remaining science objectives by recovering the last of the OOI moorings. I got to hop on the A-frame, one of the lifting cranes aboard the ship that’s hydraulically powered to assist with moving operations, to help bring in the moorings and the science instruments hosted on the cable. These moorings can get up to 2830 meters meaning the recoveries can take several hours as all that cable needs to be pulled in using a series of winches. I also helped secure some of the instruments on deck after they were taken off the cable. The ship’s deck has holes all over so that the instruments like the buoys can be bolted down. I included some more background on OOI’s mission further below.

Map of the completed survey area, including the previous moorings (#9) and the ones we just deployed (#10). Zoomed out photo next to Greenland for context. 

For personal projects, I cleaned out the computer racks on the ship with a can of aero-duster and a handheld vacuum, shadowed the OOI crew while they were pulling in the moorings and hopped on the A-frame, cleaned out the PC02 filter and learned how to use the ship’s ELOG or their online record-keeping spreadsheet, replaced the syringe on the tubing that flushes out the temperature sensors on the CTD, helped the engineers repair the LARS (Launch and Recovery System) crane for the CTD since there was a loose connection in the wires that control the magnetic limit switches for the docking head, got a tour of the engine room by one of the engineers and got to crawl around in all the nooks and crannies, added CTD waypoints to OpenCPN (maritime chart plotter software), got a walkthrough of the OOI gliders and the online interface the scientists use to communicate with their acoustic modem and Iridium satellites, practiced soldering and built a new termination ending on some practice 0.322 CTD cable wire, secured the chairs in the computer lab using bungee cords, and practiced some Python coding. I’m also editing a timelapse video of the engineers servicing one of the engines since it reached the end of its lifecycle.

QOW: What are we even doing out here, anyway? Aka the NSF Ocean Observatories Initiative (OOI) 

The National Science Foundation (NSF) OOI is a collection of ocean monitoring platforms in the Atlantic and Pacific Oceans. For this trip, our focus is on the Global Irminger Sea Array off the southern tip of Greenland (highlighted with the arrow in the photo below). The Irminger Sea Array is part of two global arrays. The locations for the global arrays were chosen to target areas that were under-sampled based on challenging sailing conditions like high winds that make it harder for research vessels to visit and collect data. The benefit of having high latitude observations is that these areas provide key insight into ocean circulation processes which can help scientists understand large-scale processes like climate change better.

The Global Irminger Sea Array has four moorings, each of which is anchored to the seafloor. In between the moorings, gliders (autonomous underwater vehicles) move in between the moorings to fill in data gaps in between each platform. The gliders communicate to the moorings via an acoustic modem which is then transferred to OOI’s servers via a satellite. What’s really cool is these moorings also have acoustic sound releases that cause the cable to detach from the anchor so we can pick them up.

For the three subsurface moorings (labeled #1, 2, and 3), once the acoustic releases have been triggered and the mooring is released from the anchor, the crew hooks the red buoyant buoy to bring it in. At the end of the mooring are a series of green buoyant balls that help the mooring to come to the surface to relieve the strain on the ship’s winches.

For the yellow surface buoy mooring (#4), the order is in reverse: the crew has to grab the buoyant glass balls first and then finally wrangle the surface buoy once the rest of the cable has been secured. The rescue boat is deployed to attach a cable to the surface buoy to help bring it onto the ship. I included some photos showing the recovery process for both types of moorings below.

For the subsurface moorings:

The buoy comes up to the surface once the acoustic release has been triggered so the crew can hook onto it.

Then, using the A-frame and a series of winches on deck, they bring in the buoy and the rest of the mooring.

For the surface buoy:

The rescue boat is deployed so the crew can hook up a line to the surface buoy directly to help wrangle it back on the ship with two points of contact (one on the bottom as part of the mooring, then one on the buoy). Source: Croy (SSSG/Marine Technician)

Recovery of the old buoys was just one step – we had to both deploy the new moorings AND recover the old ones, all while working under a tight weather window. Suffice to say I’m amazed at all the crew and science party have pulled off!

For more information on OOI: https://oceanobservatories.org/ 

Week 3 – Haley Holcomb


As predicted, we did not end up being able to launch last Saturday. The weather was too severe to work with the vehicle out on deck, so I took the time to update my Matlab script for my weather predictions. Since I first wrote it, I have been inputting new data as I receive it each day and therefore making my predictions more accurate as time goes on. As the day progressed, the weather began to subside, enough so that we could do some light work on deck drilling holes into a bracket that would hold the bottles for the SUPR water sampler. The SUPR (Suspended Particle Rosette) sampler consists of a flowmeter, a pump, a valve, and 14 bottles to take individual water samples throughout Sentry’s dive. The pump draws water to be fed into the valve, which has 14 positions for each of the 14 bottles. Because the bottles go into the water full of DI water for neutral buoyancy, the flowmeter is necessary to have record of the amount of water that was collected.

The following day, we were finally ready to prepare for the first dive since the storm had hit. We removed the Nortek to make space for all of SUPR’s components and took off the lead that had been used to account for its weight. I also watched as the lead mechanic replaced a centering spring in one of the wings, which have to be replaced about every 6 dives and are critical to Sentry’s performance. I made two sets of weights, and each weight comprises of 72lbs of steel. There are three of these in each set: two used to descend, and another dropped to ascend. We concluded this busy day with a deck test. It was so exciting to have things back up and running after the storm as downtime seems to pass pretty slowly here.


On the day of the dive, we secured the tubing and flowmeter for SUPR. After some ballasting calculations, we put 8lbs of lead back on before conducting the pre-dive. Because we were launching at midnight, I had some downtime in the afternoon and used it to write a Python script to search through data from the ship so that I could include real-time wind speeds in my Matlab script. The next day, while Sentry was in the water, I started a new book and read until my 8pm watch shift. Because things were going very smoothly, the expedition leader gave me some tasks to keep me busy like estimating where in the tracklines we’d be when it was time to come off bottom and how much battery we would have left when we began that ascent. My shift always takes place during recovery, so I’ll be inside for the post-dive and outside for the pre-dive and launch. I really enjoy being able to see all aspects of the deployment because I do really like the software side of things and get to see how everything connects.


We had a quick turnaround as we recovered at midnight and were launching again at noon the next day. The scientists had collected their samples from the SUPR bottles, so we resecured them to the vehicle before preforming the deck test and pre-dive tasks. Once Sentry was back in the water, I decided to use the time to make my Matlab script more efficient. I had been inputting the new data I collected each day as independent matrices, but as time went on, my script was getting really long and I was having to copy and paste the same loops each morning just to change their variable names to the correct date. I decided to go through the script and stack the data from each day into just a few 3D matrices and use a nested loop to iterate through each day, eliminating many lines of code and greatly reducing the time it takes me to update it each morning. At the end of the night, I finished my book from the previous day and started the first few pages of a new one.  

Because we launched during the day, I had an 8am watch. When I showed up, the mission had just gotten to a point where the previous person on watch had started to command the vehicle to leave its tracklines. Because this is more involved and a mistake could be critical, they decided to stay on until we came off bottom. During this time, I met with the expedition leader to go over my weather project, and he gave me some helpful advice about how to word my outputs to be more clear and concise for a user, and suggested that I begin to include my observations of the actual wave height during the day. I had been making calculations on the offsets between different forecasts for both wind speed and wave height, but the ship only had real-time data for wind speed. Now that I’ll be observing the height of the waves, I will be able to tie it all back to actual conditions and best predict when we can launch. When it was time to ascend, I took watch and stayed inside for the post-dive once again. While I was inside, we found out that a Canadian research vessel is also in the area and we’d have to change our dive schedule because they’ll have an ROV at our dive site. Instead of beginning a 24-hour dive at midnight, we’d launch at 8pm and come off bottom at 6am. We prepared for this quick turnaround by performing the pre-dive right after the post-dive and had a short break before putting the SUPR bottles back on, conducting the deck test, and launching. This was the first time I played a critical role in the launch and it was very nerve wracking, but went well. I had watch from 1:30-4:00am and then met back up with the team a little before 6:00am to prepare for recovery. It was hard to wake up for watch, but after a cup of coffee there was no way I was going to nap before I had to be ready on deck. When we began to ascend, I took over watch again, got breakfast after the post-dive, and finally fell asleep. There is another storm coming in, so we won’t dive again until Tuesday and I’ll have this weekend to catch up on some rest.


Week 2 R/V Neil Armstrong: Crazy Space Weather

08/31/23 – 09/07/23

Prince Christian Sound

I’ve gotten in the groove of things on the ship. The OOI crew deployed the large SUMO-10 buoy along with the whole mooring system. We had a low-pressure system move in so we had to hide out in Prince Christian Sound, Greenland which was STUNNING. We hung out at the entrance of the fjord for a while before going on a glacier hunt and sailing farther into the channel. The blue streaks on the icebergs were amazing to see as they floated by. My favorite glacier was one that stopped at a cliff and had a waterfall coming over the side.

Iceberg with blue streaks cutting through, one of the glaciers we saw, view from the bridge.

As if seeing glaciers wasn’t enough, we also saw the northern lights!! On the first night, I saw what I thought was a faint cloud but it turned out to be the aurora borealis. The sky contained green clouds that night. Then the second night, which was when an incoming solar flare was predicted to happen, we saw a faint light behind the mountains that looked like light pollution you’d see on the horizon. But then the light magnified and streaks shone across the sky, wiggling like green snakes. The crew stood out on the bow and in the bridge watching the lights in the sky. The coolest part was looking straight up and seeing the streaks of light directly above you like there was an alien spaceship trying to pick you up. The lights danced across the sky, and at one point I saw streaks of red mixing in with the green as they were painted across the sky. It was a magical night. 

Aurora lights in the sky. My camera picked up more of the green light than we saw in person.

Besides geeking out over glaciers and the northern lights, I 3D printed covers for the Debubblers in the lab to block the light and reduce bacterial overgrowth in between their cleaning maintenance. I also cleaned out the PC02 filter which was full of krill, cleaned the transmissometers, cleaned the forward pump with Emily which was full of mussels and barnacles (yum), practiced Linux with MIT’s text-based adventure game Terminus, prepared the CTD for deployment as the resident “bottle fairy” and practiced radio commands to the winch operator, practiced more Linux with OverTheWire’s Bandit Wargame, refilled the deionized water containers with Milli-Q water, learned from one of the WHOI scientists about the Winkler titration method to look at dissolved oxygen in the water samples from the CTD, and continued working with the 3D printer to create feet to secure the new Cricut craft printer.

Question of the Week: What are the northern lights, and why do they form?

The northern lights, also called the aurora borealis, are an atmospheric phenomenon of dancing lights. Galileo coined the term aurora borealis after Aurora, the Roman Goddess of Dawn, and Boreas, the Greek god of the north wind. In the south pole, the same atmospheric effect is referred to as aurora australis, named after the Greek god of the south wind. Auroras form due to an interaction between energized particles from the sun and Earth’s magnetic field. The Earth has a magnetic field based on the way its molten, iron core circulates that redirects incoming solar particles. Energized particles from the sun hit Earth’s upper atmosphere and are deflected by this magnetic field towards the north and south poles, which then excite molecules in the atmosphere to produce a dizzying array of colors. There was green and red in the aurora I saw since the solar particles excited oxygen and nitrogen molecules, creating green and red colors respectively.

Fun fact: auroras happen on other planets too! These planets also have magnetic fields and atmospheres.

Source:

https://www.space.com/15139-northern-lights-auroras-earth-facts-sdcmp.html#section-northern-lights-faqs-answered-by-an-expert

Week 2 – Haley Holcomb


The first of Sentry’s dives was one of two “engineering dives” meant to ensure that all of our instruments were behaving as expected before any scientific data was collected. Before this first dive, I put the remaining skins on the vehicle and dummy cables on its chargers before I watched as the team took it out of its cradle and a crane lowered it into the water. I really hoped to see a whale on this trip and actually got to see one right before this first dive, setting a good precedent for our operations. I reassembled the cradle as Sentry descended and then took my first shift on watch. We have to take note of things like the vehicle’s position, velocity, heading, and battery percentage every fifteen minutes, as well as the time of any abnormal behavior or commands we send to it to be referred to when looking back at the data. When I was relieved from watch, I got to take my first break until Sentry began its ascent. One of the members of the crew was responsible for connecting the forward tagline as the crane pulled the vehicle up from the surface and I got to be involved in the recovery by grabbing the pole from them once this line was secure. During the post-dive maintenance, I comped and bled the servos, junction boxes, and thrusters and replaced one of the burn wires, which are a last-resort method of dropping Sentry’s weights to bring it back up to the surface.  


I helped conduct each element of the deck test before the second engineering dive, which is a test of Sentry’s various components before its mission. I had taken part in this in the previous dive but felt like I was finally able to get a good understanding of everything that was going on. We transmit a specific frequency to each of the two acoustic releases and listen for a chime to indicate that it was received. The drop motors must be visually inspected to ensure that they are free from any wires so that weights can be released without obstruction, and must hold in place when commanded to do so. The servos in the wings can be controlled either by a remote control called a “joybox” or by commands from inside. The joybox is used to back the vehicle up to the side of the boat as it is being recovered so that it can be secured by the taglines and crane. Using each method of control, we command the wings to assume various positions and watch to make sure that they respond to this sequence without exceeding each orientation and that the propellers are spinning in the correct directions. Lastly, we measure the voltage on the burn wires and load the weights. I get so excited when I see marine life and we saw a sunfish while we were conducting these tests! Before each dive, we also go through a pre-dive routine, which involves enabling the iridiums and strobes, unplugging the charging cables, connecting the hoses for the cooling system, putting the vehicle’s skins on, and removing the straps that secure it to its cradle. After we launched, I had my first solo watch shift. Upon recovery, when the vehicle was secured in its cradle, we carried out the post-dive tasks. We return it to shore power, switch it over to ethernet, reconnect the cooling lines to the hoses on the ship, and power off the strobes.


On the day of the first science dive, I got to sleep in for the first time and it felt so nice to be well-rested. I felt like I had begun to fall into a routine with the pre and post-dive so I could be more helpful and perform tasks without instruction. We added a few extra sensors for the scientists and compensated for this change in weight before performing the deck test. Usually, Sentry is used for seafloor mapping, but on this trip, we are collecting various data over hydrothermal vents. It is designed to stay a certain altitude above the seafloor, but for this objective, we wanted to command it to hold a certain depth below the surface instead. Because of this, there were many points where Sentry’s acoustics could not reach the seafloor, and we lost what they call “bottom lock”. The software in the vehicle would then lose its trackline and begin to ascend, so the person on watch had to send a series of commands from the surface to combat this.

The science dives are 24 hours long, so every day we will alternate between having missions from noon to noon and from midnight to midnight. When we launch at noon, my watch shift is from 8am to noon, and when we launch at midnight, my shift will be from 8pm to midnight, so I am always working during Sentry’s ascent. My first watch shift was much more involved than is typical, as was expected due to the constant loss of bottom lock. The team had come up with a solution where we could push the vehicle back towards its trackline with a series of shift commands to keep it inside an envelope of altitude and depth. I lost bottom lock a few times on my shift, but was able to follow this sequence and keep everything under control. At the very end of my watch, the commands to keep depth stopped working, so I was instructed to abort the mission early and went outside to help with recovery. When the vehicle was secure, I came back inside and asked the software engineer if I could watch his post-dive tasks such as securing power and communications and recovering all of the collected data. I was really interested in these “inside operations” and asked to continue to shadow him when I was not needed outside. Once all of the data was downloading, he told me it would be a bit of a long wait, so I went down to the gym for the first time. It was really nice to relieve some stress but, while it does add an element of fun, running on a treadmill while the boat is rolling was very disorienting. I did some yoga as well, but keeping my balance was even harder. When I returned, I helped test a pump for a methane sensor that a scientist wanted to add to the vehicle for the following dive. It wasn’t working on our vehicle power, but she was able to connect it to another one of their instruments and get enough power that way and we deployed again at midnight.  


When the vehicle is in the water, the days are more relaxed. I had been given a project that would allow us to better predict when the weather would be too severe to launch by monitoring the disparities between different forecasts and the actual conditions, so I began to think about how I wanted to execute that. This became more intriguing as we awaited an approaching storm. While I was working, I got a message that someone had seen dolphins outside and ran out in the rain to watch them. There were about seven of them playing right up next to the boat and it was a kind I had never seen before. They were so tiny and cute. I came down to the lab for my 8pm watch shift, but things were really hectic as Sentry was failing to follow its desired path. I watched for a while as this was troubleshot, but they were not confident that their commands were successful, so they aborted early and I eventually took over to monitor the ascent. The weather had started to worsen and the science team still needed to launch a CTD, so this ended up being a good decision all around. Because I was already on watch, I got to carry out the inside operations for recovery and really enjoyed being more involved in the software side of things again. This time, I stuck around as the data came in and it was actually really cool because I got to briefly see each Matlab plot pop up before the successive one did, giving me a much better idea of what the science party is using Sentry to measure.


The next morning, we cleaned up the deck in anticipation of the incoming storm. I decided to do my calculations of the offset between weather reports on Matlab and began to input my data and write that script until the waves began to increase in height and I started to feel seasick. I got off my computer and joined the people working outside, who were preparing for the installation of a water sampler called SUPR. We began some tests, but there appeared to be a ground issue so the scientists took SUPR back inside and we started to set up its tubing. Being outside was not helping much, so I went down to take a nap and woke up feeling a lot better. Because the weather didn’t allow us to launch that day, a few people gathered in the lounge for a movie night.

The wind is continuing to pick up, so we refrained from launching once again today. I started my day by inputting some new data into my weather script and then did my laundry. I returned to the lab to see if I could help anyone, but because SUPR was still being fixed and the weather was so poor, there was no work to be done. I went down to the gym and rejoined everyone for dinner. Tomorrow will most likely be a lot like today, but we hope to launch again when the weather subsides on Sunday.


Week 1 R/V Neil Armstrong: Off to Greenland

Seljalandsfoss waterfall in Iceland 🙂

08/24/23 – 08/31/23

This week has been a whirlwind! On the 24th, I arrived to the R/V Neil Armstrong, docked in Reykjavik, Iceland. Since then, I’ve been familiarizing myself with the ship’s spaces, meeting the crew, and working on some projects. I met my mentors, Emily and Croy, who I’ll shadow for my internship. One big task the crew had to complete before sailing to Greenland was repairing the main crane. Since the seal on the inner piston for the extender arm was broken, we had to hire two cranes to hoist the crew up there and a crane to lift out the inner piston part.

Cranes to hoist the crew and the inner piston. Source: Croy

Since joining the ship, I’ve been working on side projects to support the science party. I’ve used a power drill to replace some of the rusted nails on the CTD wooden frame with stainless steel ones (aborted since the screws kept stripping as they weren’t the right type), took off the tubing from the flow-through station in the lab to clean the tubes with fresh water (and tried to remember how to put it back on), attached the CDOM (Colored Dissolved Organic Matter) fluorometer on the CTD rosette with a mounting block that Emily 3D printed, studied computer networking fundamentals and Linux, and helped prepare the CTD for a deployment and captured water samples from the Niskin bottles once the rosette came back up. Emily also taught me a nice hack to fill in stripped screw holes by breaking wooden toothpicks in the hole so the screws have something to latch onto.

In terms of life on the ship, I’ve been amazed at the variety, flavor, and amount of food on board. On my first night here, we had chocolate cake for dessert and there has been a whole spread of snacks on the counter up for grabs (Cheetos, gummy bears, candy bars!!) The food is really incredible and for me it’s a good sign to see that the ship goes above and beyond for the crew’s morale. There’s also CHEESE THIRTY, a charcuterie board that happens every day at 1530. You read that right. 

Some other cool things that happened this week was finding out my roommate had previously worked in film as part of the camera crew for television shows including the Walking Dead. I also played disc golf with Croy and company on top of a hill in Reykjavik that overlooked the city and was framed by the mountains.

For this upcoming week, the current plan is to go into Prince Christian Sound in Greenland to avoid a storm. The view there is supposed to be spectacular so I’m really looking forward to that. I’m also looking forward to working more with the 3D printer. 

I wanted to dedicate this last section to questions I’ve had since joining the ship:

What is the R/V Neil Armstrong, and why is it named after the astronaut?

The R/V Neil Armstrong is an oceanographic research vessel owned by the United States Navy and operated by Woods Hole Oceanographic Institute. The ship was named after Neil Armstrong, the first man to walk on the moon and a Navy veteran. Naming the vessel after Armstrong harkens back to the time when the space program named their space shuttles after WHOI oceanographic sailing vessels, such as the space shuttle Atlantis named after WHOI’s R/V Atlantis. In turn, the new class of research vessels including R/V Neil Armstrong and its sister ship R/V Sally Ride with Scripps Institution of Oceanography (like the WHOI of the west coast) were named after astronauts. During The R/V Armstrong’s naming ceremony, the Secretary of the Navy Ray Mabus said:

“Naming this class of ships and this vessel after Neil Armstrong honors the memory of an extraordinary individual, but more importantly, it reminds us all to embrace the challenges of exploration and to never stop discovering.” Secretary of the Navy Ray Mabus (source)

Upcoming questions:

What is the OOI Science Mission?

What does a marine technician do?

More to come 🙂

Week 1 – Haley Holcomb

I made it! After a few delays from the hurricane in California, I flew into Portland and stayed in an airport hotel for the night. The next morning, I met up with the Sentry Team in the lobby to drive down to Astoria together. We stayed one more night in a hotel there before boarding the Atlantis.

The crane we were meant to use broke down, so we had a bit of delay getting our equipment on the boat. I got to watch the team’s software engineer update Alvin’s GUI while we waited, which was really interesting to me because it closely aligned with the work I’d been doing back home. I also unpacked my room and got a tour of the boat. Seeing how big it is really calmed my nerves and I got even more excited for the weeks ahead. To make better use of our time, we ended up carrying a lot of our things onto the ship, but eventually Sentry and the vans made it on with a new crane.

Once we had everything we needed, we unpacked our lab and set up the equipment. My first mechanical task was to connect and test the hoses for Sentry’s cooling system. I also put batteries into the beacons and strobes and cleaned their o-rings. We ended the day with dinner on shore and a quick stop at a department store before returning to the boat for our first night sleeping on board.

The next morning, I wiped our drives and assembled Sentry’s recovery poles. The stores came in, so we formed an assembly line to get the food from the freight elevator to the fridge/freezer/pantry. Everyone on board has some really cool stories from other research cruises and I had a great time chatting with them and getting to know everyone between loads.

When that was finished up, I comped and bled Sentry’s servos, junction boxes, and thrusters. Bleeding for air is necessary because any air in the lines would compress upon descent, potentially allowing seawater into the system. I also installed the wings as well as the beacons and strobes I had assembled the previous day. We took a break from working on the vehicle for an orientation meeting to discuss life on the boat and to meet all of the scientists. Afterwards, my roommate and I secured the van for sea. This turned out to be very hard work with so many heavy boxes, but by the end, I felt like I had finally familiarized myself with the layout of the boat.

We set sail around 10:00 this morning. I was really worried about getting sea sick, but (knock on wood) the water has been relatively calm. My chief complaint is that I wore one of those behind-the-ear patches and must have accidentally touched it and then touched my eyes in my sleep last night because I’ve barely been able to see all day. My pupils are enormous. While I was fine helping with mechanical things, I couldn’t read anything for the life of me and it was very unsettling. 

The electrical engineer on the team taught me how he pots cables and I ballasted Sentry with lead weights. We also participated in a safety orientation and drill for emergency ship abort procedures. I was shown the emergency exit closest to my room, which happens to be through the engine room, so I got to briefly see that. I also installed Sentry’s propellers and learned how to tie up taglines. 

We did a deck test that involved turning the beacons on and off, using a controller to test the propellers/wings, and checking the drop weight triggers. The day culminated in a meeting where the scientists shared their goals for the trip and I have a much better understanding of our mission now. Yesterday was a very long day so we’re turning in early tonight, but we’ll be up bright and early for Sentry’s first dive tomorrow!


Week 0 – Haley Holcomb

Hi! My name is Haley and I’m going to be graduating from the University of California, Santa Barbara in June. I am studying mechanical engineering and am interested in developing underwater vehicles and oceanographic instruments. 

I am flying into Oregon on Monday to meet up with WHOI’s Sentry Team and board the R/V Atlantis. We will be at sea from Wednesday the 23rd until September 17th supporting research on the Endeavour Hydrothermal Vents. We will first collect CTD profiles directly over the two sites to calculate the heat output at each vent and to collect plume samples. Once that data has been recorded, we will deploy AUV Sentry to survey the area around the sites. 

I have gained some experience with this equipment working with the Coastal Oceanography and Autonomous Systems Lab at my school. Our most recent project culminated in a trip to Maryland to conduct field work with our AUV on the Chesapeake Bay. This was my first experience working on a research vessel and I loved every minute of it, but we were only at sea during the day so my trip with the Sentry Team will be my first time living aboard one. I’ll attach some pictures from that trip!

Week 0 R/V Neil Armstrong: Intern Introduction

Hi everyone!

My name is Cassie Ferrante and I will be the UNOLS-MATE intern on the upcoming R/V Neil Armstrong voyage. We’re scheduled to sail from Reykjavík, Iceland to Greenland, then back home to Woods Hole, MA from the end of August through September. Our main science objective is to recover and replace the NSF Ocean Observatories Initiative (OOI) Irminger Sea Array in an area southeast of Greenland.

Some background on me:
In 2020, I graduated from Colgate University in Upstate New York with a degree in Marine-Freshwater Science. Due to covid travel restrictions, I participated in my study abroad program after graduation. In 2021, I joined Sea Education Association’s Ocean and Climate Program, sailing from California to Hawaii. I absolutely loved sailing and couldn’t wait to get back on the water. Last year, I sailed on the NOAA R/V Okeanos Explorer as an explorer-in-training, a similar internship program to this one except more of a focus on seafloor mapping. Since then, I’ve participated in two terms with the NASA DEVELOP program in Wyoming and Alabama using NASA Earth satellite observations to address local environmental concerns. 

I’m thrilled to join the Armstrong and to meet everyone soon!! I’ll be traveling around Iceland for a few days before meeting the boat. 🙂

Week 4: Distinguished Visitors + Transit to Astoria, Or.

Hey all, this is Mija Wheeler from the RV Atlantis with the Alvin Crew. Since my last post, the R/V Atlantis had the opportunity to host distinguished visitors from ONR, NavSea, the National Science Foundation, and WHOI. During this time, the Alvin Ops team was doing two “bounce” dives daily for a total of three days. This means that once the sub is in the water, there was usually about 30-45 minutes before the A-Frame (or the device that is used to hoist the sub off deck and into the water) had to start its warmups again. I’ve included a picture of the A-frame in action.

It’s safe to say that as tiring as the bounce dives were, the robust efficiency of the Alvin Ops team and the Atlantis crew were on point during this trip. I think one of the highlights of talking to the distinguished visitors was learning about all the opportunities that WHOI and the various government departments have for interested students. Another fun highlight is that during the required safety briefing with all the new people on the ship, I was pulled up as the practice dummy for putting on the emergency evacuation suit! So, I have included some silly photos of me being strapped into what I’ve been told is called the Gumby suit and attempting to do a shaka!!

Once we dropped the distinguished visitors off in San Diego, we left port the next morning on a transit cruise to Astoria, Oregon. At the time of writing this, we have been in transit for approximately 3 days and have experienced a couple of days of mildly rough weather to the point where we had to officially “secure for sea”.

Shortly after leaving San Diego, before leaving California waters, we made a quick stop to recover an errant elevator that was unable to be recovered from a science cruise on another ship a couple of years ago. Outside of that, transit hasn’t been busy, so I spent some time talking to the data people to learn more about how operational data from Alvin is processed and plotted for human use. I think I might even get to learn a bit of Linux so I can attempt to make my own so I’m very excited for the coming weeks.

Till then, aloha!! 


Week 3 – We finished a science cruise!!

Hey all, this is Mija Wheeler aboard the R/V Atlantis from the Alvin Submersible Operations Crew. There was no post last week because the flu went around the ship which inevitably resulted in several members of the Alvin Ops Crew (including myself) being out of commission for about half the week. Thankfully, no one tested positive for Covid so for all things considered, I’m still in good spirits.

Since my last post, we have officially completed my first science research expedition and demobilized in San Diego.  During this cruise, I was charged with the setup and operation of two deep water underwater cameras called MISO cameras, which are effectively Go-Pros and an external battery inside a water-proof stainless steel casing. During this trip, I used these cameras to capture video footage of all the dives from the perspective of the right manipulator arm and take images from the brow of the sub every 5 seconds. The scientists used all the pictures to create a Timelapse of the dive, so that at the end of every dive they could have a 2-minute video to show all the surface members what happened over the course of the 5-hour dive.

Currently, I don’t have any of the MISO camera photos saved to my hard drive, but I did get some pictures of the animals and bacteria that were pulled up from the bottom of the ocean. I have included my favorite below.

With nearly half of my internship complete, I can confidently say I’ve had the time of my life and have learned so much. I’m excited to see what new things I learn or see next week, till then ALOHA!


.    

Page 7 of 16

Powered by WordPress & Theme by Anders Norén