Category: Host Page 32 of 89

Week One – Stuck at port

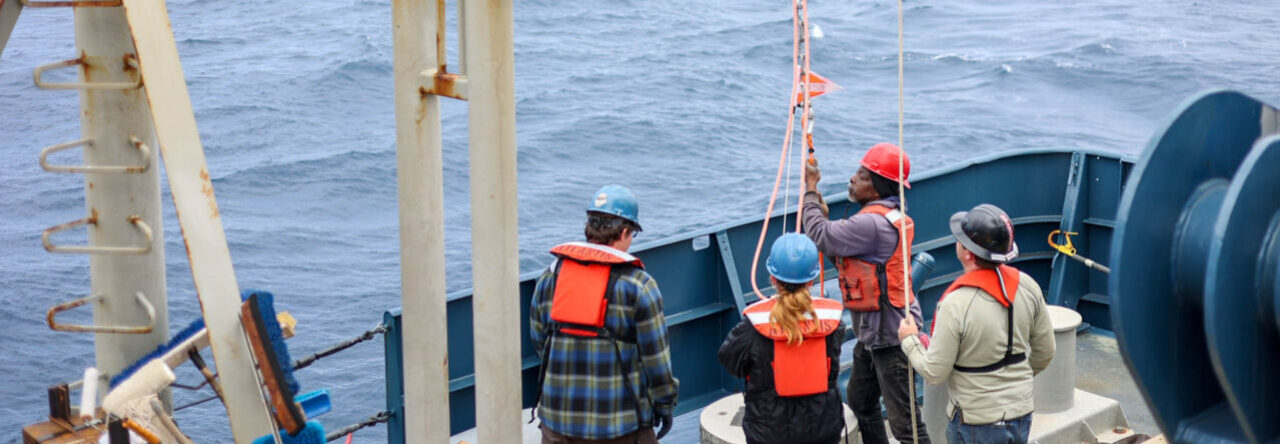
The first week has been a wild ride. When I arrived the crew and the lead scientist were in the process of mobilizing the operation. I helped with loading equipment and food supplies. The crew has been very welcoming and friendly to me. Above is a picture of Huxley, he taught me how to crip a cable loop on the end of a steel cable. We were scheduled to leave port last Saturday but as we were in the process of taking off there was an issue with the breaker for the bus coupler that sends power to the drives. The engineers have been working hard to solve the issue but now we are waiting for a replacement part from Italy. The hope is that the part will be here before this weekend and we will be off on the mission. 

This unfortunate event has allowed me time to see the town of Lewes, Delaware. I have explored the state park and visited several beaches. My favorite place has been the “conch hole” as I like to call it. Pictured above is that area and me holding one of the conch snails. I have never seen live conch snails and there are so many of them. They are very interesting to me, some are even larger than my fist. I found out that they can live up to 30 years. 

I am very excited to get underway and hope that the engineers are able to get the ship back up and operational. 

Until next time, Jake the Intern

2023 Long Term Internship!

Hello and good morning! I am this year’s long-term internship recipient! I wanted to jump on and introduce myself. Last summer I was honored to complete the MATE short-term internship where I ventured out with WHOI’s ROV JASON team to tackle sample collection/exploration/data acquisition of areas around the Blanco Fracture Zone and Mount Axial from May 23rd through July 5th, 2022.
This year, I will again be setting sail with WHOI onboard the Thompson, off the coast of Newport, Oregon. The first three months-ish (June 29th-Sept 24th) will be at-sea, and then I will travel to the east coast and finish the final three months (Oct 1st- Dec 23rd) at the WHOI facility where I get the opportunity to be apart of the maintenance/rebuild of JASON. 
I just graduated with my associate’s degree in the Marine Technology Program at Northwestern Michigan College. I cannot wait to get back out with WHOI and look forward to keeping you all updated on the adventures along the way!

Week 2 aboard Hugh R. Sharp

Hello again everyone! I hope you are all doing well. it’s been quite an exciting and eventful time since my last update. In the past twelve days, I have been exposed to many new and interesting things about the Sharp, its crew and equipment, and the logistics of setting up this type of survey.

Let’s start from the beginning. On May 9th I landed in Salisbury Maryland, and was greeted by the oceanographic manager for the University of Delaware’s Earth, Ocean & Atmosphere College. He drove us roughly an hour to Lewes, Deleware where the Hugh R. Sharp is docked. We got our first tour of the vessel and the surrounding area and were shown where we would sleep for the night. 

The Hugh, pre-mobilization: 

The following day we met most of the operational crew and started the process of loading up everything we needed for the survey. The Habcam and wet lab were hauled on the R/V using a huge crane, and I helped set up and secure a few things with help from the techs onboard. It was a pleasure to work alongside such professionals and I was in awe of how much they were able to get done in one afternoon. They were extremely accommodating and even asked us if we wanted anything specific for the grocery list (I wanted some minestrone soup and trail mix).

Hugh R. Sharp (left) alongside the Delriver (right): 


On the eleventh, we got to meet most of the science team (the rest of them would arrive at a later date) and had fun crimping 1/2″ steel cable. It would be the secure point between the LCI 90 port wench system and the Habcam. This wench would be used to slowly lower the Habcam in the water column once it was time for deployment. It took us a couple of tries to get it right, as the cable was pretty oily and hard to handle. 

One of the crimps that didn’t make the cut (didn’t have a long enough “tail”): 


I also learned a lot more about the different functionalities and sensors that the Habcam is equipped with. It’s a really unique piece of hardware that has port/starboard sides-scan transducers and a forward-facing BlueView sonar (plus a multitude of other oceanographic sensors). I’ve actually had some experience working with this sonar and it’s one of the most advanced I’ve seen so far, it’s got an extremely quick refresh rate to the point where you’re basically seeing objects in real-time in a 180-degree swath. 

BlueView mounted to the front of the Habcam for obstacle avoidance: 

The next day was for shopping! The generous folk at UDEL paid for any necessities we forgot to bring and got us a complete set of high-quality wet gear! The awesome thing is that we get to keep our stuff even after the survey is over. The wet gear will keep us warm and dry during the long days on the dredge shoveling scallops and what-have-you. Once we got back from our shopping trip we helped restock the R/V with all the groceries they got for the survey ($3,600 worth of food!).

Then, May 15th rolls around. The big day! We donned our immersion suits (I volunteered to do it for the safety drill, it was pretty heavy and hot) and went over the process of the abandon ship protocol. After several briefs, we prepared to leave the dock at 1600. We had a twelve-hour steam directly to the first fisheries station and I signed up for the night shift (2400-1200). This is where stuff turned downhill. The vessel’s breaker that routed power to the drivers (which powered the thrusters) had a mechanical failure due to years of wear and tear from the movement of the ocean. Everyone who could help immediately went to work to diagnose and remedy the issue, I stood by watching the troubleshooting process, and tried to learn as much as I could without getting in the way. 

After a couple of days of being dead in the water and the engineers working late into the night, they found the issue and discovered there was practically no way to fix it without getting a completely new breaker. The breaker we needed was only made in Italy of all places, and they immediately ordered a new one with expedited shipping. This brings us to the current day! Since the part that we need will roughly take a week to arrive, I have been spending time exploring and hanging out in the beautiful city of Lewes, Deleware. The crew has also taken us around town and showed us all the cool spots and sights to see, so I’ve been having lots of fun. 

Though I am a little saddened that we will miss the first leg of the trip, I understand that these things happen and it’s better we discovered it now at port instead of being several miles offshore! Plus we still have the whole second leg of the trip, where we get to stop by Woods Hole, Massachusetts and I’m really excited for that! Anyways, that’s it for now! thanks for reading and I’ll be here again next week to update you all on how it’s going, take care and have a good one! 

– Alejandro Dominguez 


Intern Introduction

Hello everyone! 

My name is Alejandro Dominguez and I’m a third-year student at Northwestern Michigan College. I am currently pursuing an associate’s and bachelor’s degree in marine technology, and I plan to graduate with my associates in the spring of next year. 

When I have some free time from college and work, I like to spend it doing stuff outdoors. Morel hunting, bird watching, hiking, camping, and so on, as long as it’s out in nature! 

I was originally drawn to the program because of this. The promise of hands-on work with oceanographic equipment on the Great Lakes was all I needed to hear before I signed up! 

Three years later I would be writing my first blog to introduce myself as an intern aboard the Hugh R. Sharp for its annual sea-scallop survey! It’s almost surreal as I would have never imagined myself to reach this point. I leave tomorrow morning and I’m extremely humbled and grateful for this once-in-a-lifetime opportunity. I owe it all to my instructors and peers at NMC, as well as the extremely kind and generous people at UDEL (Maria I’m talking about you!). 

I can’t wait to tackle this adventure with my fellow classmate and friend, Jacob Stremlow who will also be an intern aboard this survey! 

Thanks for taking the time to read this, and be on the lookout for weekly blog posts from Jacob and me about the sea-scallop survey aboard the Hugh R. Sharp! 

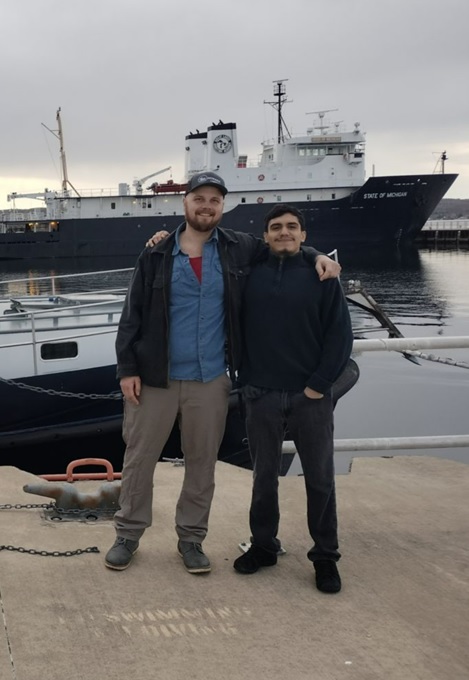
Jacob (Left) and me (Right) outside GL Campus 


Week 5: HYDRO, Mooring, and Goodbye!

Tuesday May 2, 2023

The first half of the day consisted of A-frame testing. In the previous tests (see blog post…) it was noted that the A-frame warped while being tested with weights. 

These weights were approximately 4,600lb combined. When picked up by the dush 4 winch and A-frame, it would significantly warp. Today was to test possible causes for that. They did that by positioning weights and lifting on either side. This would isolate the problem. If the A-frame warped equal amounts with the weight lifted on either side. 

The hydraulic differential appeared to be a symptom of the problem. One of the differentials was struggling much more than the other. When the weights were tested on the Aft side, these differentials were the same, indicating that the problem lies with the bow hydraulics. 

After break Rory took me on top of the bridge where the satellites and antennas are mounted and I got to go inside one of the domes!

Apparently these are some really big domes for this size ship. You can see the picture of me inside them for comparison. We have to make sure these domes are turned off while working on them because of the radiation produced. 

After that I went back to working on the code from before. There’s always room for improvement with coding. The current task is to get the code to be able integrate with not just the TX520 sensor but all devices that produce serial data with an RX232 input. Technically the input should be easily changed but it’s needed to go into the code and manually change the pin ID’s.

The goal is to make this completely automated with no action required from the user. 

Essentially we want it to:

Connect to sensor

Cycle through baud rates until the correct one is found

Write the incoming data to a list 

Print these out on an LCD and update while new data is sent in.

This is an interesting project but it is definitely time consuming. Seeing as I only have 6 days left and 5 of them will be spent at sea I’m not sure how much more time I’ll be able to allocate to this. 

May 3, 2023

Today we had a day-long HYDRO station cruise with BATS. It consisted of a few CTDs at various depths along with a glider recovery. Apparently the glider notified land that there were a few leaks relinquishing it inoperable. Here you can see the glider (yellow) getting hooked so we can bring it in on the boat.

Very simple day. We docked at St. George’s and are waiting on the weather forecast to see if we’ll begin the mooring deployment tomorrow or wait until Friday. As it stands, it seems that we will be waiting until Friday to deploy in better weather.

The bridge notified us that the wind sensor was not functioning and so Oban and I went to see if there were any obvious disconnects in the wire. This lead to us going “Aloft” and Oban strapped into a harness to climb up. I wanted to do it but my inexperience would have just had me climbing up there for fun. You can see how high he climbed in the picture below. 

Nothing of significance was noted in the wire connection and so we decided to call it a day. 

May 4, 2023

Dock day! Today we did any last minute maintenance around the ship that can be completed in a day. 

Oban has contacted the company that made the weather sensor in order to get any guidance for possible troubleshooting. It seems that they might need to send it in for re-calibration.

Most of the day I was altering my code that I wrote to read out data from NMEA sensors. My goal today was to get it to automatically change baud rates once the correct sequence of data is found. I got a rudimentary code working but it wasn’t working well enough to put to use. At this point the code started having more and more moving parts in it and so I decided to move things into a finite state machine in order to get it to work. That’s a task for tomorrow though. 

May 5, 2023

Today we deployed from St. George for the mooring cruise at 7:30 am. 

We were in transit for the first half of the day and since there wasn’t much to be done I took the liberty to go down into the engine room and talk to the chief engineer to see if I could learn a thing or two. 

Afterwards Rory showed me how the satellites connect to the internet, and then how the internet is managed. It’s surprising how many components go into this but yet seem so simple. 

We deployed a CTD once we got to the approximate position of the mooring so we could do some samples at depth and again at surface. This will help to calibrate the findings on the mooring. After it was deployed we had quite a bit of down time so I picked up my code again in order to implement the finite state machine. It took a bit of testing but so far it’s working! I only have one sensor with one baud rate to test it against but Lydia might be able to get me another this evening or tomorrow. When we were docked I could use the GPS input sensors but since we’re deployed it’s not a great idea to mess with any coordinates that are imperative to the boats navigation system. 

We just recovered the CTD and are now done for the day. Finally tomorrow we will be able to recover the mooring! 

We have to get up before the sun rises to begin recovery because the first thing that we do after releasing the mooring is “see” where it is. Since there is a flashing light on it it’s “easiest” to see it when it’s dark. I’m quite excited. 

I will likely be on the first morning shift so I can see all the goings-on required for this, which means I also will likely get to break earlier.

Fingers crossed nothing goes wrong this time. 

We recovered the mooring!!!! It’s fascinating how long it is (over a mile in length) and it’s hard to imagine just how deep the water beneath us really is, but this recovery definitely helps put things into perspective. Interestingly, the way that the mooring is recovered here is to pick it up from the bottom and wind the wire in up to the top, stopping for wire replacements and instrument removal. Here you can see the final buoy and ADCP being recovered on deck.

In the morning (before daylight) the ship turns off all transmitting acoustics so that the scientists can turn on their own acoustic transmitter (this is what I helped set up in the straza tower a week ago). This is because they need to “communicate” with the bottom mooring release in order to tell the mooring to drop the weights and resurface. Having multiple acoustic transmissions going at the same time is similar to trying to hear one person when many are talking all at once. essentially messages consisting of:

 “Are you awake?” 

“Yes I’m awake” 

“Please drop the weights” 

“Ok”

Once the weights have been released, it takes approximately 5-7 minutes for the top of the mooring to surface and about 40-50 minutes for the rest of it to surface. Now everyone working right now needs to go up to the bridge and look for the mooring. One of the crew mates, Henderson, was exceptionally good at spotting it. Once it is spotted, the person that sees it will hold their arm with hand open, gesturing towards where they saw it and try and get as many eyes on it as possible. Each of the instruments attached to the mooring have their own set of buoyancy spheres that will raise and so it is important to see each of these segments (with different colors and numbered spheres) in order to know where to pick the mooring up. After we located it, the whole mooring surfaced, and we picked it on a grappling hook, then is where the winches and lines come into play. 

It took us a total of 7 hours (a little on the long side) but this was because we had to replace FOUR 400 meter long lines. We also had 2 tangles which impeded progress significantly. This is where things get more confusing, because you can have a whole mess of wires going in every direction with a bunch of tension on each of them and you need to decypher which ones go where. The scientists have each of the segments of wire labeled so that’s how we would tell where it’s supposed to go on the mooring. It was really cool to see all that tension transfer from one line to another in order to remove and repeat the processes. We had to replace a lot of the segments of wire which was done after a certain number of deployments or after significant damage from a tangle. In order to replace the segments, we had to reel it onto the big squid (large winch we were using), tie off the rest of the mooring with a deck line to hold the tension, unhook the line and wind it onto an empty spindle. Unfortunately, the spindle that holds all the wiring when loading and unloading it onto the mooring, is HAND OPERATED. 

It requires a lot of arm strength. Apparently they’ve got a compressed air powered spooler ordered but it won’t arrive for quite some time, and so hand spooling it is in the meantime. I had a critical job on this recovery- taking care of the diapers. Each of the links on the mooring need to be covered with a protective cushioned cloth so that when it’s tension-loaded onto the winch, the shackles won’t bend or pierce the wire around it. I’m so glad I got to see the mooring recovery as I was worried that our last trip cancellation might not allow me this. 

Tomorrow we will be re-deploying the mooring which includes dropping a 2,500 lb weight at the end of the line and having it sink down. Apparently this process is much more straight-forward and therefore runs faster. We will see if that rings true tomorrow. 

May 7, 2023

Today was mooring deployment day! It took us around 5 hours to get everything in the water. Similar to yesterday it was a lot of taking tension on and putting it somewhere else in order to attach different wires, buoys, and instrumentation. 

Hello Bermuda

Hey!
My name is Devin and I am 27 years old. I have a bachelors degree in marine biology from the University of North Carolina at Wilmington and I am about to graduate from the marine technology program at Cape Fear Community College. Im a cat mom and avid reader. I work at a local taproom in downtown which is hard cause I love my mornings but have to work late. Im originally from a small town in northern Vermont. I moved to North Carolina at 18 and fell in love with the ocean and ocean sciences. I’ve done three short overnight at sea trips on the RV Cape Hatteras through CFCC and have absolutely loved everything about it. Although im nervous about going for the month I’m super excited for all the experiences I will have and all the people I will meet. 

Introduction

Hello everyone,

I am a student at Cape Fear Community College in the Marine Technology Program. This is my first internship and I’m excited for this opportunity. I will be a marine technician intern onboard the R/V Marcus G. Langseth for a month. We will be conducting seismic sonar, ctd’s, gravity coring, and retrieving obs’s. We set sail out of Norfolk, VA.   

Week 4: Coding, Coding, and more Coding

Tuesday April 25, 2023

Today I’ll be doing as much as I can. I’m continuing the cyber-security course that Rory directed me to and I’ll be doing some future job/ internship searching as well. 

Lydia gave me an Arduino to play with! 

I managed to get the ultrasonic sensor working and then moved to hook up the LCD monitor. I managed to give it a little test (it didn’t work) but by that time it was dinner so I decided to pick it up in the morning.

Wednesday April 26, 2023

Today I spent the day working with the Arduino Lydia had given me. 

LCD monitor worked

Lydia brought me a new bread board

Wrote code to integrate the two LCD and Ultrasound

Now the goal was to get usable data from the Sensor. This turned out to be more confusing than anticipated as I’d never done it before.

Here we have the Weather sensor Vaisala TX520 (it’s upside down because I didn’t have a mount)

I managed to get data by plugging directly into the Arduino- but it was unusable because it was just unorganized strings of numbers. I may have been able to go off of this to see if I could decipher the content but decided to try the RS232 Shield instead because the sensor has information on using a RS232 port (*SPOILER* This took an additional 3 days to fully understand and connect the RS232 Port with the sensor).

Also definitely spent much longer than necessary figuring out how to integrate the shield with the arduino… (Brianna the shield goes on TOP of the arduino and conveniently plugs into all of the ports!!!… Almost as if it was incredibly obvious and DESIGNED that way… In my defense… the plugs were covered by styrofoam and therefore I could not see them.)

Managed to get more data but this time it’s coming out as SYMBOLS. Ugh. At this point I had been staring at the screen for hours on end and needed to give my brain a break.

April 27-28 & May 1, 2023

I’m going to group the next 3 working days into one because they were all focused on the same thing, and the progress was painfully slow despite the immense amount of effort put in. Unfortunately, I’ve gone above and beyond implementing this sensor with an arduino at the cost of precious precious time, patience, dignity, and reputation (oops). Hopefully my mentors aren’t too disappointed. 

Some lessons that I have learned and utilized from this experience (that may seem obvious) I summarized below: 

Do as much research on all the components present as possible before sinking too deep in the problem.

Ask questions, ask questions, ask questions.

Keep good notes of the progress, and link to any useful information you’ve found.

Create a general plan of attack/ blueprint of method and change whilst you go along.

Don’t get hyper fixated on the one problem. It’s easy to just look at the problem at hand and come up with a specific solution. However, it’s innovative to see how this problem might be similar to other problems, and even more creative to adjust your solution to be applicable to many problems (Thank you Lydia!). 

And so without further ado I’d like to present to you… 

The Arduino LCD Output NMEA Sensor reader (TALONS (ignore the r)) 

(Yes I included more words so I could make a catchy acronym. As you can see that didn’t work great, but the initial alternative was “ANTS” which came out as “Arduino NMEA The Sensor”… which wasn’t making a whole lot of sense.)

Now if you say it’s silly that there’s an acronym within the acronym (NMEA, a legitimate acronym: National Marine Electronics Association) then I don’t know what to tell you other than I put blood, sweat, and tears (minus the blood) into this program so there.

Though anticlimactic, here is the result of all that work. A LCD monitor that displays sensor data! Note that this code is (hypothetically) integratable with all sensors that have an RS232 connection and NMEA formatting. Also, the string displayed is not the full data string output by the sensor and so options of either getting a larger LCD or having the data scroll will be explored. 

I will not be including the code here because looking at it makes my eyeballs sad.

Over the weekend (April 29-30) I took full advantage of the bike and went exploring blue holes, caves, and mangroves! 

ON THE NEXT EPISODE OF “Brianna On a Boat” (BOB)…. haha

We will see what adventures Brianna can find herself in with not one but TWO cruises this week. A quick day-long hydro-station on wednesday and then the MOORING CRUISE Thursday-Monday! 


Thank you for your time 🙂

Introduction: Harpoon Seabring

Ahoy there!

My name is Harpoon Seabring and, with a name like that, I was bound to end up in a role like this. I just graduated from Florida Institute of Technology with a BS in Ocean Engineering. While at Florida Tech, I worked in a lab that studied biofouling, with a focus on the application of ultraviolet-C light to prevent fouling growth. I was also given the opportunity to spend a few days aboard Florida Institute of Oceanography’s R/V W.T. Hogarth to test an ROV designed by myself and my senior design group. Despite being rained on every day, despite being caught in one of the first tropical storms of the hurricane season, and despite getting very seasick after one night of particularly high waves, I had an amazing time and wanted to go back out to sea as soon as possible.

Even in my free time, I spent as much time on the water as I could. Florida Tech’s sailing team took up most of my free time, and I served as the Vice President for my final year of schooling. I live in Virginia now and, at the present moment, it’s still a bit too cold to go sailing (at least with my total lack of cold weather gear). My free time is occupied by rock climbing and cycling instead. 

I look forward to working with BIOS. My time working in a lab has no doubt left me with a skillset relevant to this internship, and I hope to be a useful member of the team. Likewise, I look forward to learning about the research performed onboard and about the instrumentation the Atlantic Explorer comes equipped with. I plan on pursuing a career on marine vessels, and I believe this experience will be one big step towards that end.


Week 3: Ship tasks, cruises, and Maintenance Docked

April 17, 2023

Since we got back to shore we’re back to an 8-5 schedule. 

Today we didn’t have too many things to do. Oban and I were tasked with replacing one of the VHF antennas on the bridge which sounds easy, but was much more time consuming than we thought it would be. We only had to remove the old antenna and wire, and install the new one, but this took all day. Things just kept going wrong (of course). Taking down and installing the antenna was the easy part, it was the removing and reinstalling the new wire that was difficult and we’re still not done. This was mostly because it required feeding the wire through tight spaces and tubes and running it through ceiling panels which was cramped, and stuffy and took a lot of patience. We even had to drill a new hole in the ceiling so we could remove the old wire. The pictures below show the antenna we removed and the little “upside-down” U shaped wire tunnel we had to feed it through. 

April 18, 2023

Today was an important day where we tested all of the winches to make sure they can handle the weights that will be used for the next cruise, and just to make sure all is working well. Doing these weight tests also works as a calibration for the readout of the tension load on the winches. This works by using a transducer to relate voltage or current running through the wire to the force that is being ‘applied’. Essentially, the winch lifts a known weight of both small and large loads to create a linear relationship with the voltage, which is updated to the winch operating system for calibration. Below you can see some of the weights we used- which were 2,500 lb TRAIN WHEELS! So cool! We then loaded them on board the ship with the crane. 

There are a lot of winches on board the ship, and they take quite a bit of time getting used to all the names, their operation procedure (more how to handle what the winches will be used on), capacities, and maintenance. I’m still getting a hang of all the names but this is what I have come to learn so far:

DUSH 5: This is the winch that we use most often because it is used to deploy the CTD. It has an approximate load capacity/ application force of around 20,000 pounds (I think) but we have a safety margin of 5,000 pounds, which I believe is because of the capacity of the wire. The CTD weighs between 1,100 pounds and 1,600 pounds when it’s full with water. The low test for the winch was around 420 pounds and the higher test was around 4,600 pounds. The winch could handle this load just fine (which *spoiler* won’t be the case for the DUSH 4 even though it’s supposed to), however the A frame seems to be significantly strained- that’s a problem for another time. 

DUSH 4: The DUSH 4 is a hydraulic winch on the port side of the first deck. This had been strength tested to 4,600 lbs less than 6 months ago, however this time it could only lift approximately 3,400 lbs- this is not up to criteria. Lydia suggested they close some valves, and after that was done it lifted 4,100 lbs- which was better but still not what she expected.

COM7: We tested this first and began with the 460 lb weight, and then maxed it out at 2,500 lbs. This was the easiest and also the most successful.

Big Squid: This was tested with the full weights of 460 lbs and the full 4,600 lbs. 

Once all the testing was done it was about 1500- break time! After that Oban and I went to finish up the VHS stuff that we had done yesterday- this included plugging the wires that we had just run into their corresponding radios. All that was left was to attach the GPS to the radio, which is necessary for a distress signal, it will send a signal to all those within the field of view that can receive a distress signal along with the coordinates. 

April 19, 2023

Today I worked mostly on UPS testing. This was a bit more complicated than I had initially anticipated, yet the directions seem simple: 

Locate the UPS

Identify any electronics that are plugged into the UPS (each of these need to be shut down and unplugged prior to testing the UPS.

Determine the Power output limit (in Watts)

Consider known electronics with power inputs good for the test and plug in.

Unplug the UPS

Time how long the battery lasts.

The first UPS that I worked on had quite a few difficulties. There were 4 things plugged into this UPS. Interestingly the first one was a desk light, which I suppose is important in emergencies so it makes sense. The other things are, 2 navigation monitors, and a “Man Overboard” alarm system. This seems simple enough except one of the wires was not labeled and so I had to trace it back to where it was, which required going up through the ceiling panels and finding where it originated. 

Before I was finished locating the other wire, the scientists came on board today to begin “mobbing” (mobilizing) all their supplies and equipment. I helped them install a Transducer to send out a signal to communicate with an acoustic release- this is what releases the mooring during recovery. Installing it involved just a few bolts and some more wire feeding and management (hurray) but it was in a part of the ship I had not seen yet! It’s on the first deck behind a door that looks like it is sealed shut and hadn’t been opened in many years. This opens to a small cavity about 2ft x 2ft square that extends down to the hull of the ship. This cavity is generally called a “moon pool” but on this ship is called the straza tower. Here you can see a picture of the transducer that we installed. 

After we were done with that, I went back to the UPS’s and managed to finish 3 of them. You can see the chaos required to figure out sources for each of the UPS. Luckily most of these wires were labeled which made it relatively easy.  

April 20, 2023

This morning, Oban and I worked on assembling the wire after it had been unplugged from the CTD for the winch tests. Managing wires is especially important on the CTD because of the conditions it is sent to. Normal wire management is to keep everything neat and organized, but managing wires on the CTD is to minimize drag and force being applied onto the wire. The way to do this is by zip-tying the wire throughout the CTD and along the metal frame. 

Unfortunately later it was determined that we needed to terminate the wire so all we had done was immediately undone. However it was really cool to see a wire termination as there are a LOT of steps to make sure everything goes properly. We took off about 30 ft of wire. Wire termination consists of attaching the winch wire to a port that connects to the CTD and also keeping everything structurally sound. Since the wire is directly attached to the CTD, it is imperative that the load is taken off the bottom part of wire where it attaches in order to keep a good connection. Once we terminated the wire we did a quick weight test and connection test to make sure we can still communicate with the CTD and that the wire can hold it too.

During these tests, the A-frame was noted to have been a bit strained and warped by the previous weight testing and so the hydraulics will need to be checked the next time there’s heavy maintenance on the ship. 

Later I went and updated many of the computers aboard the ship. This entailed doing a windows update, a chrome update, and an antivirus update. Simple enough it was just time consuming. 

April 21, 2023

Deployment day! Today we are deploying on the “conte” cruise. This cruise we will be recovering and re-deploying a 4,500 METER LONG MOORING!! :O 

We had a meeting discussing the recovery and deployment of the mooring and apparently what we do is grab the bottom end first, and then pull in all the way to the top. Now this sounds easier than it apparently is- with the process generally taking approximately 4-5 hours with a possibility of another 6 hours if anything goes wrong. (Fingers crossed that it goes smoothly.) 

Today consisted mostly of transportation and a few tests of the conte machinery. 

First we tested their acoustic releases by sending them down to 1,500 meters and seeing if the transducer would communicate with them properly. Everything worked well! It was really cool to hear these machines communicating with each other. Essentially there are a series of patterns and codes that are sent at specific frequencies to the acoustic releases and once these patterns are recieved you can listen for the response- in this case it was 4 high pitched quickly repeated “chirps.” In order to do this test we obviously needed to turn off our acoustic echo sounder- which runs at 12 MHz, similar to the communicator. After the test was concluded, we prepared for a short pump deployment.

These are going to be very similar to the pump deployments of the bats cruises where they pump water through and collect the material in a filter. 

We will be doing a few pump deployments this evening and then first thing in the morning (even before breakfast) we will begin the recovery. 

Unfortunately the cruise was postponed so we’re heading back to port for the time being.

April 22, 2023

Today we made it back to the dock and since we got back towards the afternoon we got the rest of the day off as it was the weekend. Rory mentioned that the cruises might be postponed for a week or so, and if I can get my return flight postponed as well I might be able to join them still. Working out the semantics- fingers crossed!

April 23, 2023

Today was a very quiet day, it was Sunday so we had the day off and I took the opportunity to catch up on emails and rest.

We had a nice little barbeque for dinner. It was very fun and much needed. Towards dusk I pulled out the guitar and we all sang and played songs.

April 24, 2023

Today we’re working on demobilizing and each of the techs are working on a cyber-security certification. 

I hope they let me extend my stay so I can get on at least one more cruise. 
 

Page 32 of 89

Powered by WordPress & Theme by Anders Norén